On June 10, 2026 the Pesticides Regulatory Directorate (PRD, formerly PMRA) permitted the use of drones for pesticides registered to be applied by air in Canada. Since then, a common question has been which those pesticides are, and what the volume, droplet size, and buffer zone restrictions were.
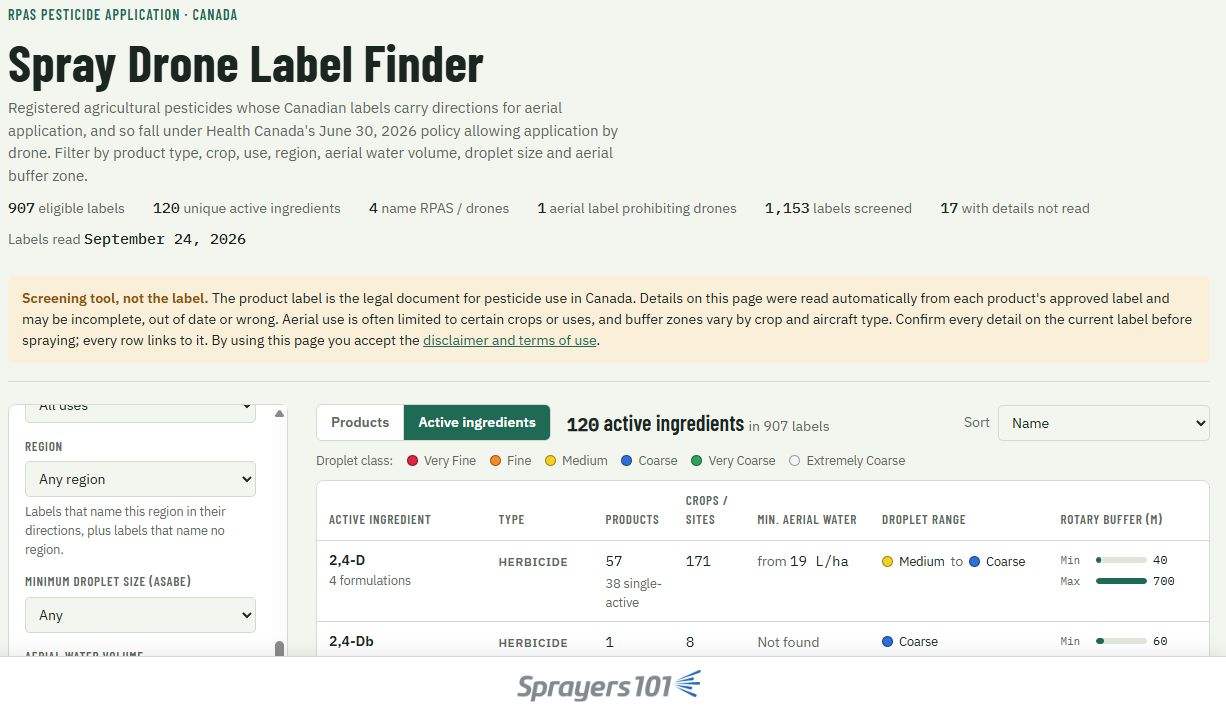
We’ve built a database that contains all products registered in Canada for aerial application. This database can be searched by product name, or by active ingredient name. The important paramaters are identified in columns. The database can be further filtered by pesticide type, crop, or region, and can also look for specific droplet size or water volume restrictions.
The database is not perfect, and will be updated over time. It is important that the original label be read to confirm the summarized information. To that end, there is a link to the label beside each product.
We’ve tested the database, but not comprehensively. Please let us know what errors you find, or how the database might be improved in the future.
There must be a separation of duties of mixer/loaders and pilots. In other words, two people will be required to spray by RPAS, someone who pilots but does not touch pesticide, and another who takes care of the mixing and filling.
Drones can only be operated within Visual Line of Sight (VLOS). A Visual Observer must assist the pilot if they are unable to maintain VLOS.
All label product rates, water volumes, droplet size requirements, and buffer zones, as well as PPE required, must be followed.
Buffer zones for rotary-winged aircraft are to be used for RPAS
There will be no new label language required. No specific RPAS instructions on flying parameters, calibration requirements, etc.
Registrants wishing to opt out of an RPAS label would need to file for an exemption with PMRA, and those labels would be revised to state “DO NOT apply by Remotely Piloted Aircraft Systems (RPAS)”
Registrants may opt to create RPAS specific labels for their products.
There are no federal RPAS-specific training or certification requirements. Those are at the discretion of the provinces.
Calibration is a fundamental step in any spray application. To apply the correct product rate, we need to know how much liquid per unit land area is deposited under the sprayer.
To conduct the calculations, either manually or through the drone software, we need to know the width of the spray swath. This task requires the operation of the sprayer under typical conditions, some kind of sampler capture the spray deposit, and a means of quantifying that deposit so the spray pattern becomes apparent. Here’s how we do it:
1. Confirm the accuracy of the flow meter
Drones don’t typically report the spray pressure of the spray mix. Instead, they report the flow rate using a built-in flow meter. The drone maintains the desired application rate by using the flow rate to adjust pump speed and engage nozzles over a range of travel speeds. Because everything depends on the flow meter, its accuracy needs to be verified.
Fill the spray tank with clean water and flush all the lines.
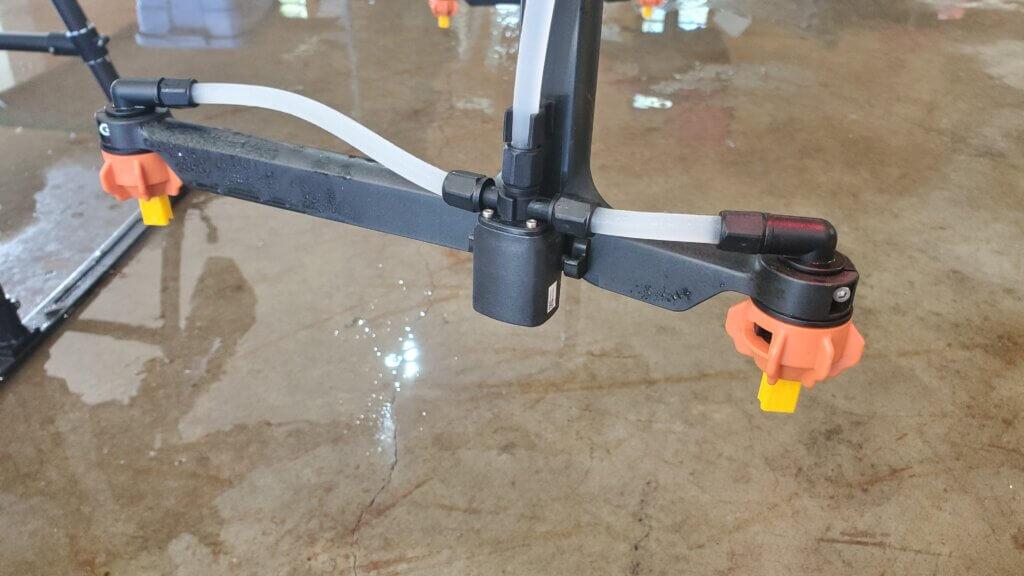
Install nozzles required for task, ensuring all nozzles are identical and in good working order.
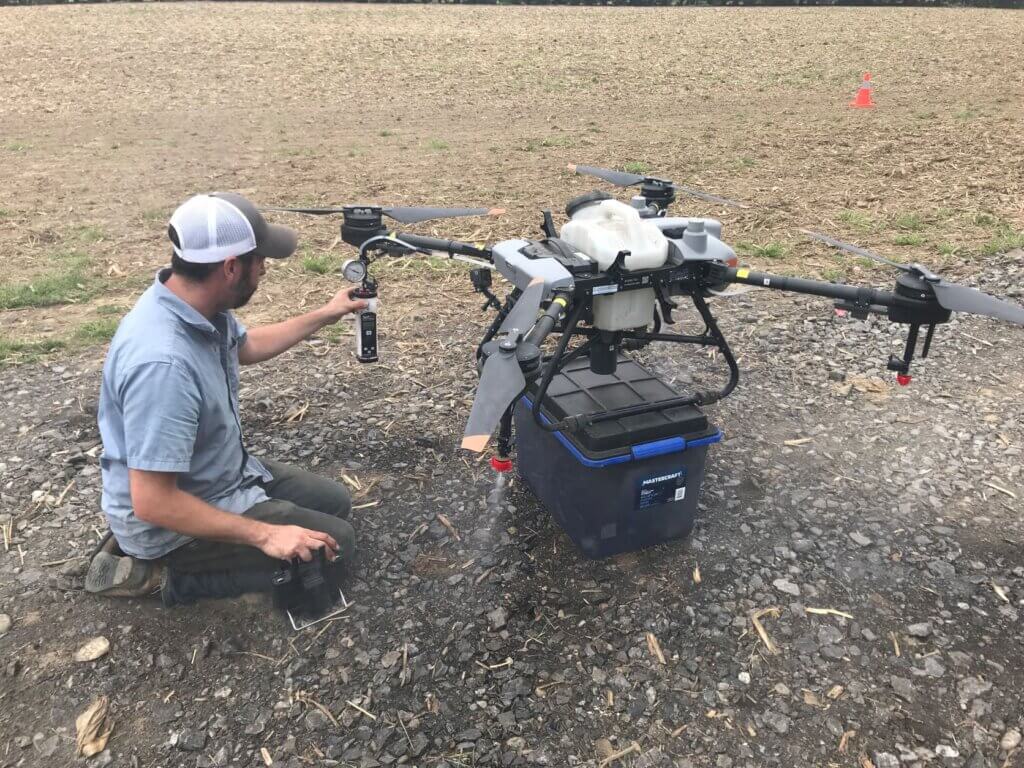
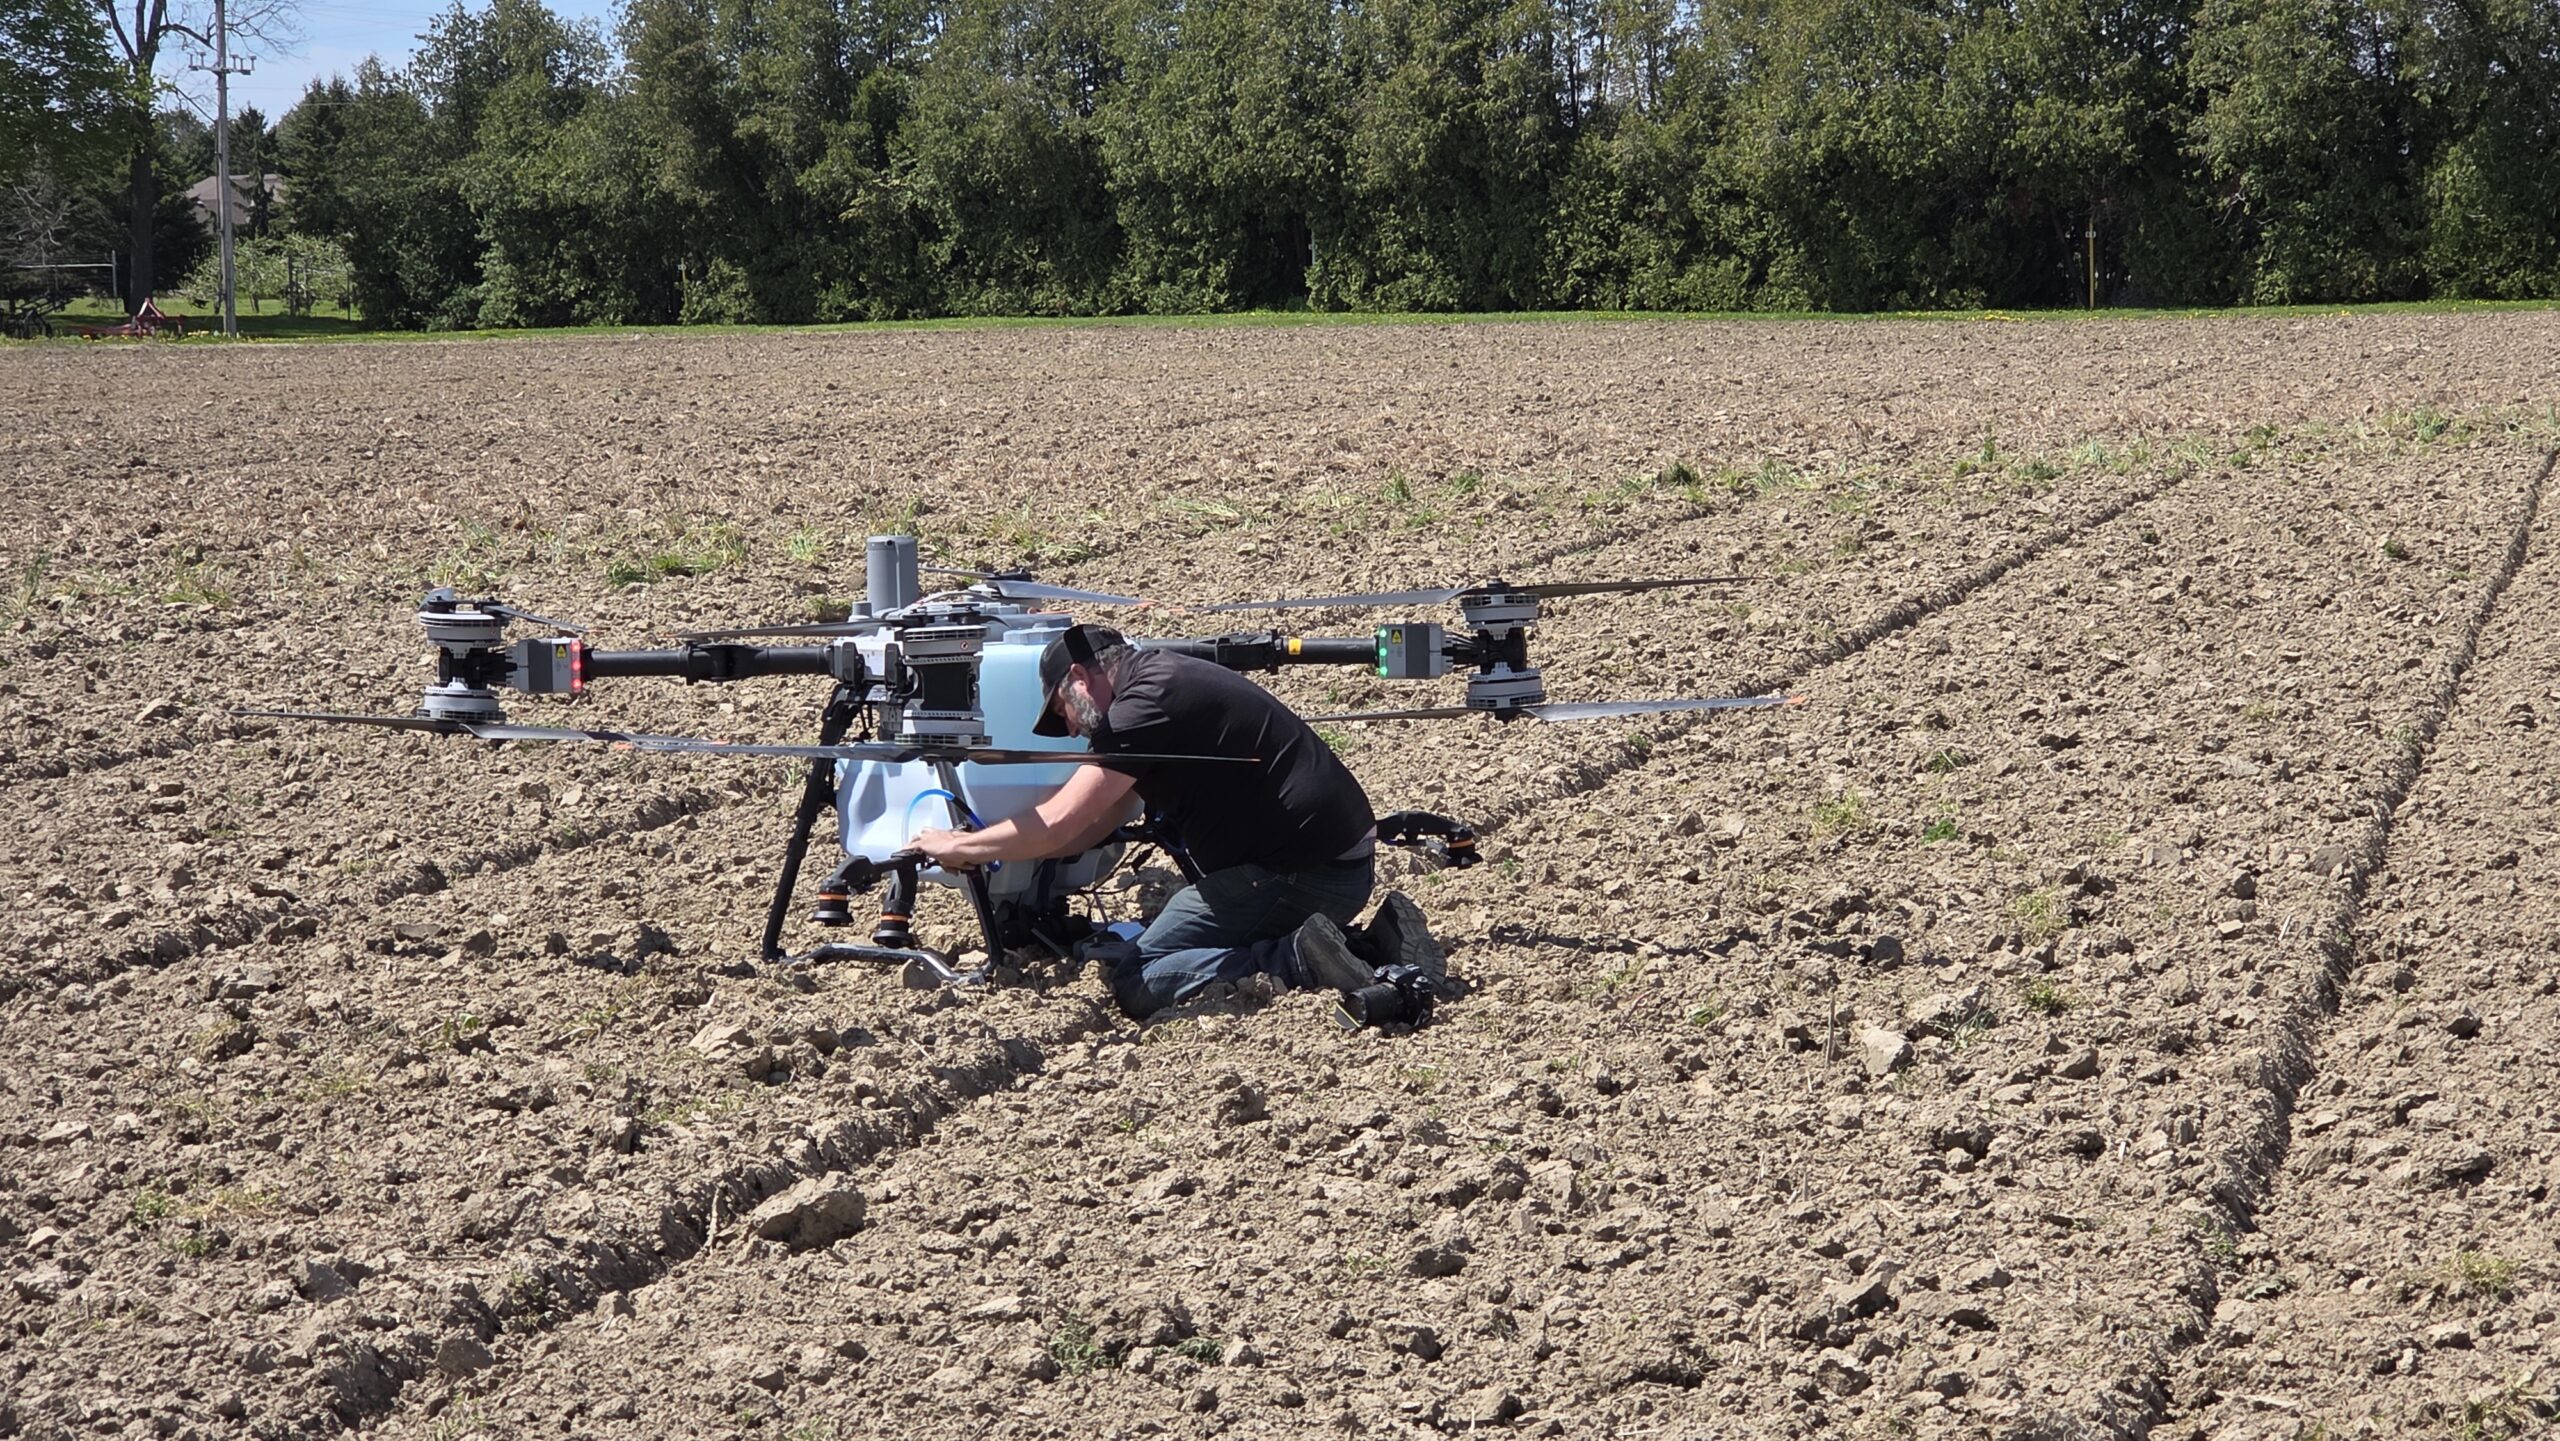
Nozzles installed on DJI T20 drone.
Select the nozzle size you installed on the spray monitor.
Purge the air from the system.
Activate the spray and wait for the flow rate to stabilize on the spray monitor. This may take a few moments.
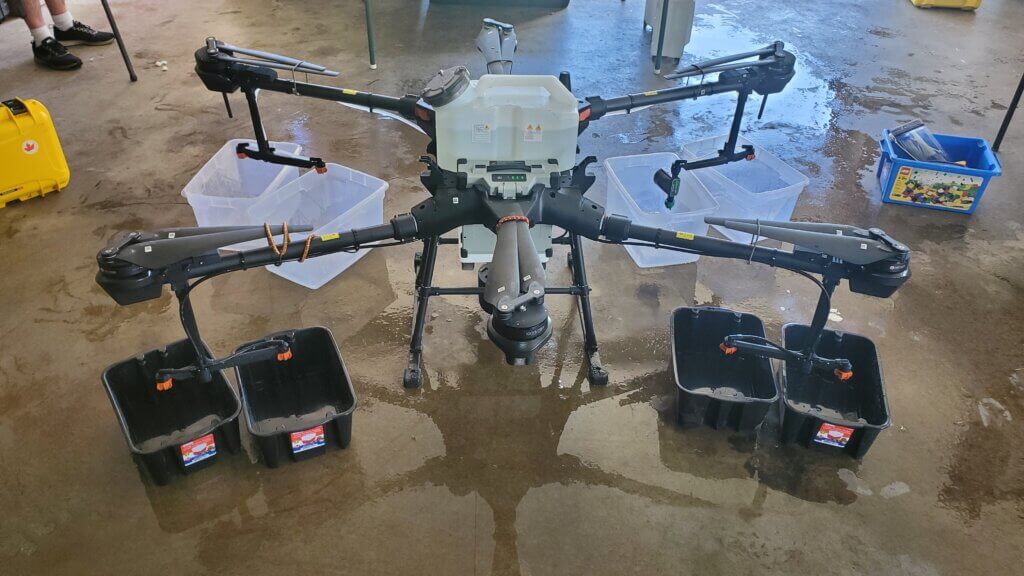
With the nozzles flowing, place collectors under each nozzle and collect the spray liquid for a fixed time, say one minute.
Capturing spray during flow meter calibration.
Ensure the collector catches all the spray. Buckets often create turbulence. Rotary atomizers make this more difficult.
When the time elapses, remove the collectors and then shut off the spray.
Unless the shutoff is very fast and positive, leaving the collectors in place during shutoff can introduce error as the flow diminishes.
Confirm that the volume collected from each nozzle was identical, and that the flow rate reported by the drone flow meter is accurate.
Repeat to ensure consistency.
Use of a Spot-On digital calibrating cup ensures that all spray is captured and it also reports the volume instantly.
2. Measure the swath width
Spray swath width is variable. For a measurement to be relevant we must evaluate spray deposition under environmental conditions that are similar to the planned spray operation, as well as use the same operational settings such as altitude, travel speed, nozzle choice, and application volume.
Spray samplers are positioned along the ground, perpendicular to the flight path. We use water-sensitive paper (WSP) because it’s readily available, fast and easy to use, and the deposits can be analyzed visually or using simple apps that calculate coverage. We create a sampling line of WSP positioned a 1 m intervals (or maybe 0.5 m for narrow swaths). The samplers should extend to twice the expected swath width to account for any swath displacement from sidewinds.
Choose a day with light, consistent winds.
Find an open space free of obstruction in the direction of the prevailing wind.
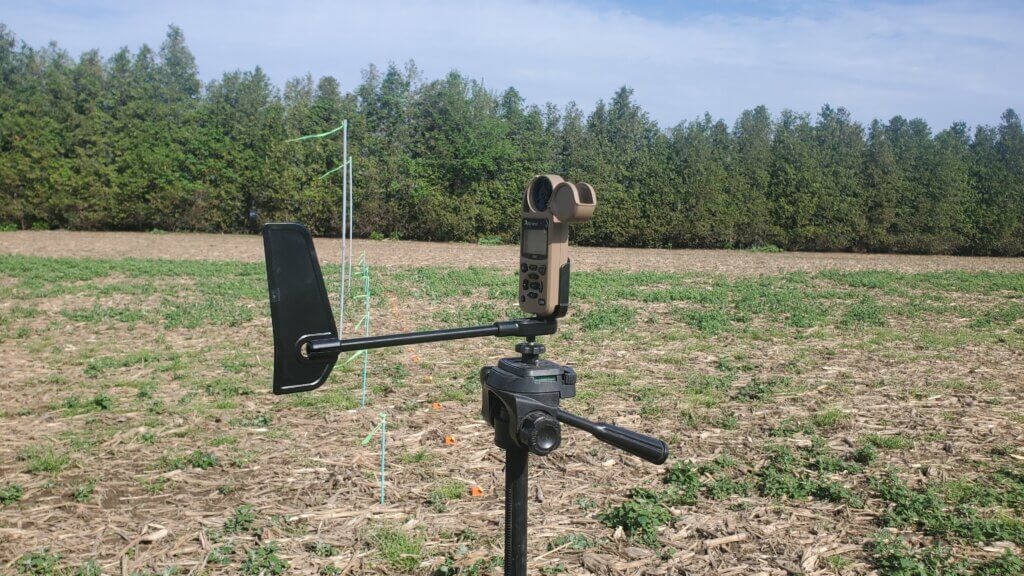
Install a weather station to document conditions during flight.
A Kestrel 3550AG or 5550AG wind meter can record weather data and download to a phone via Bluetooth.
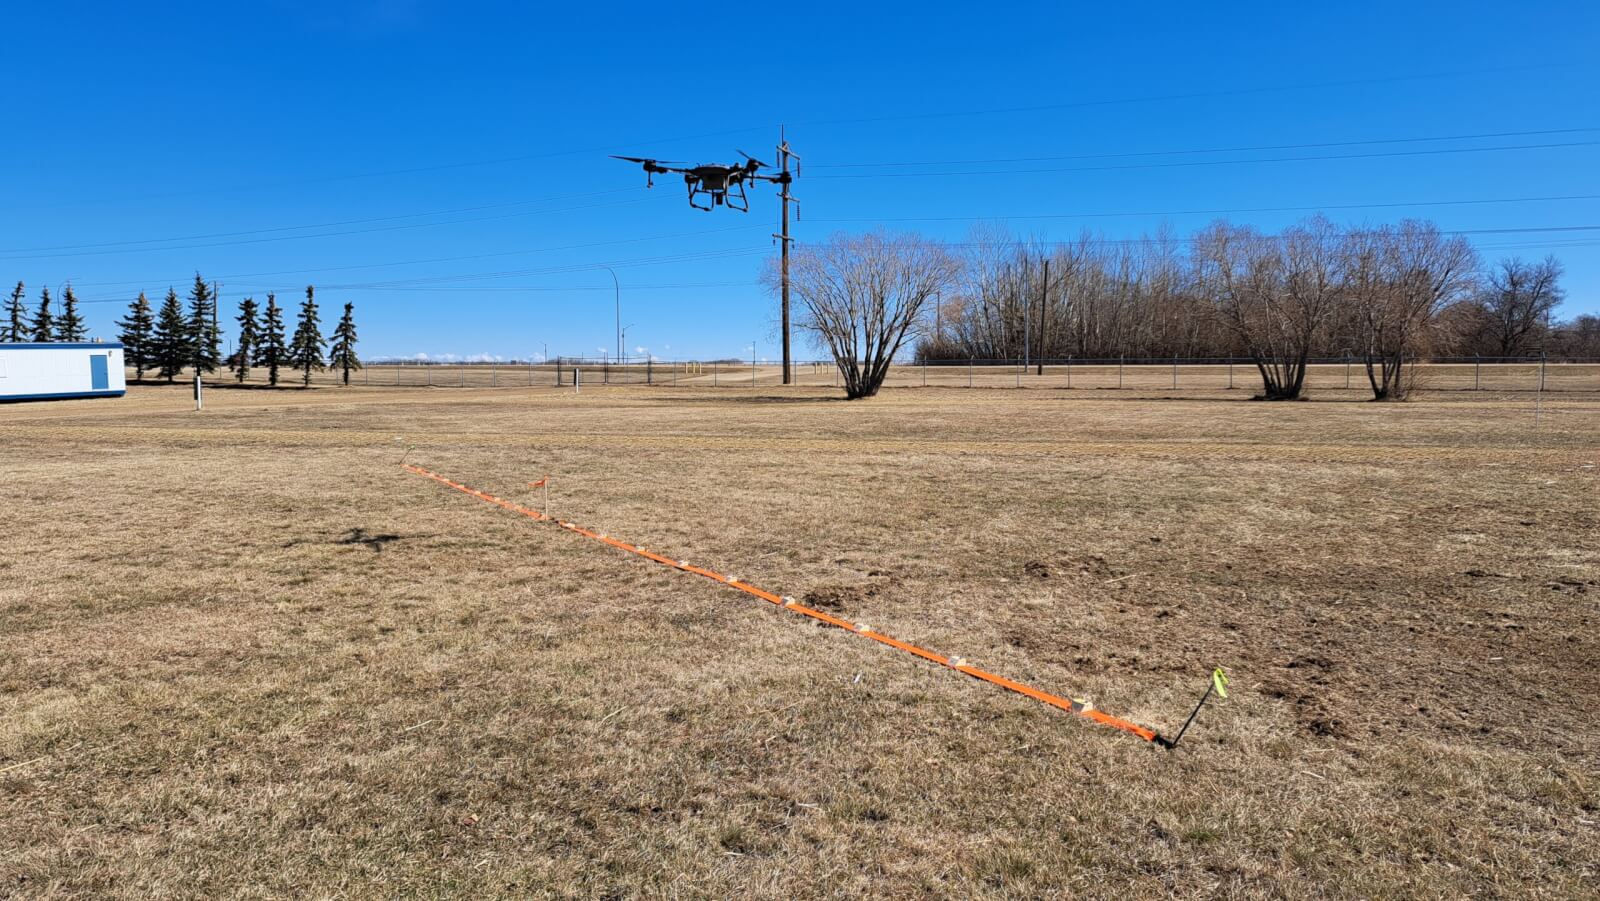
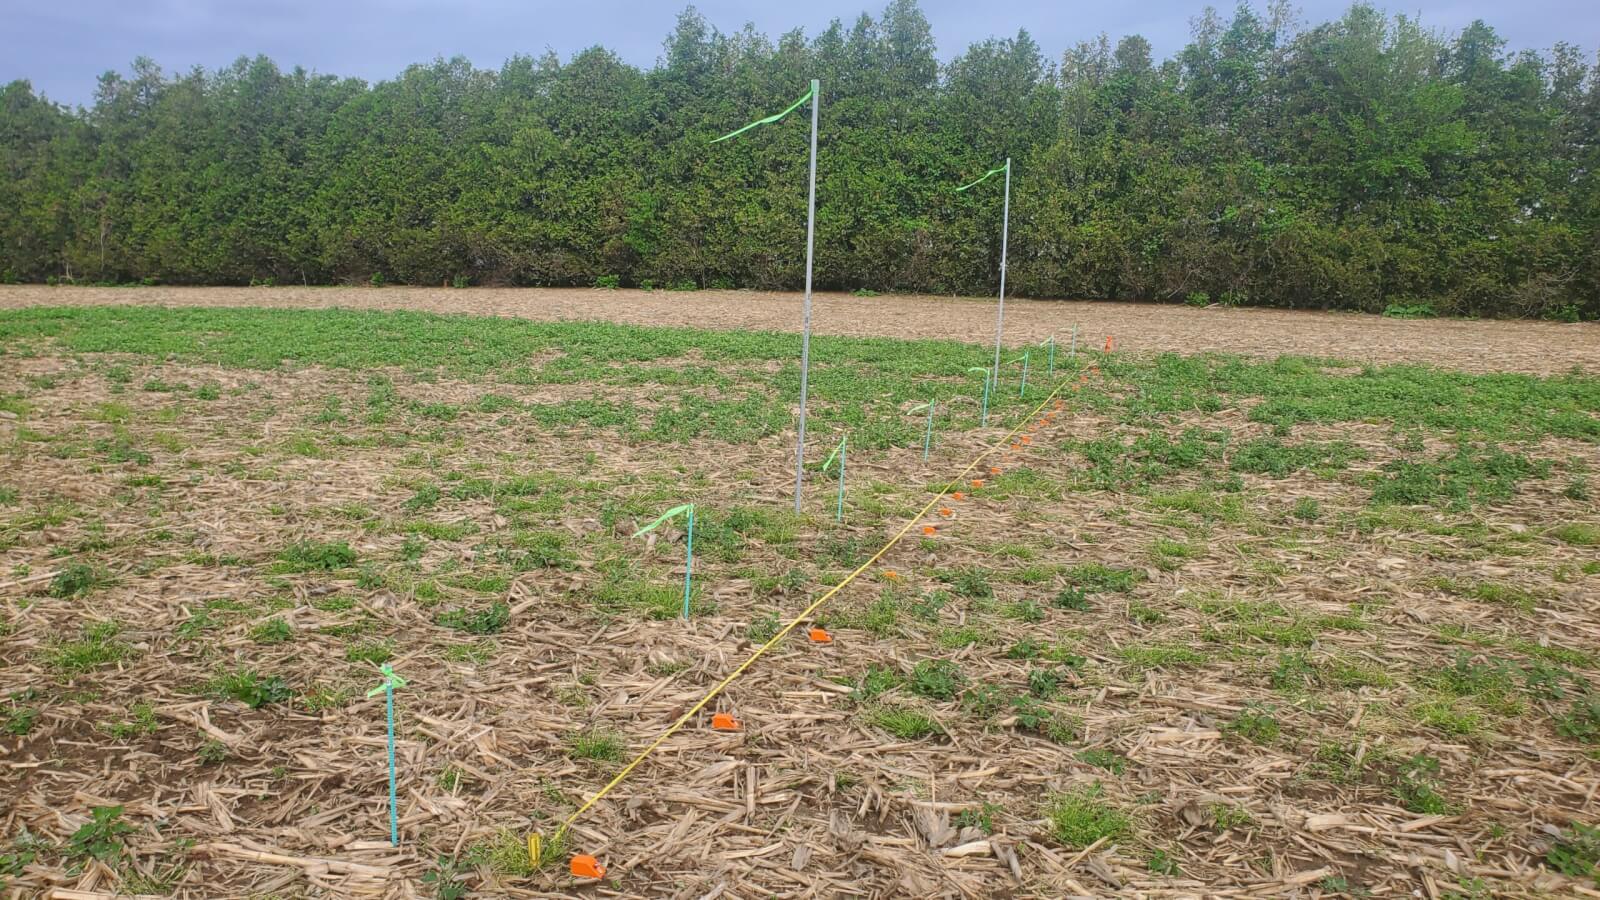
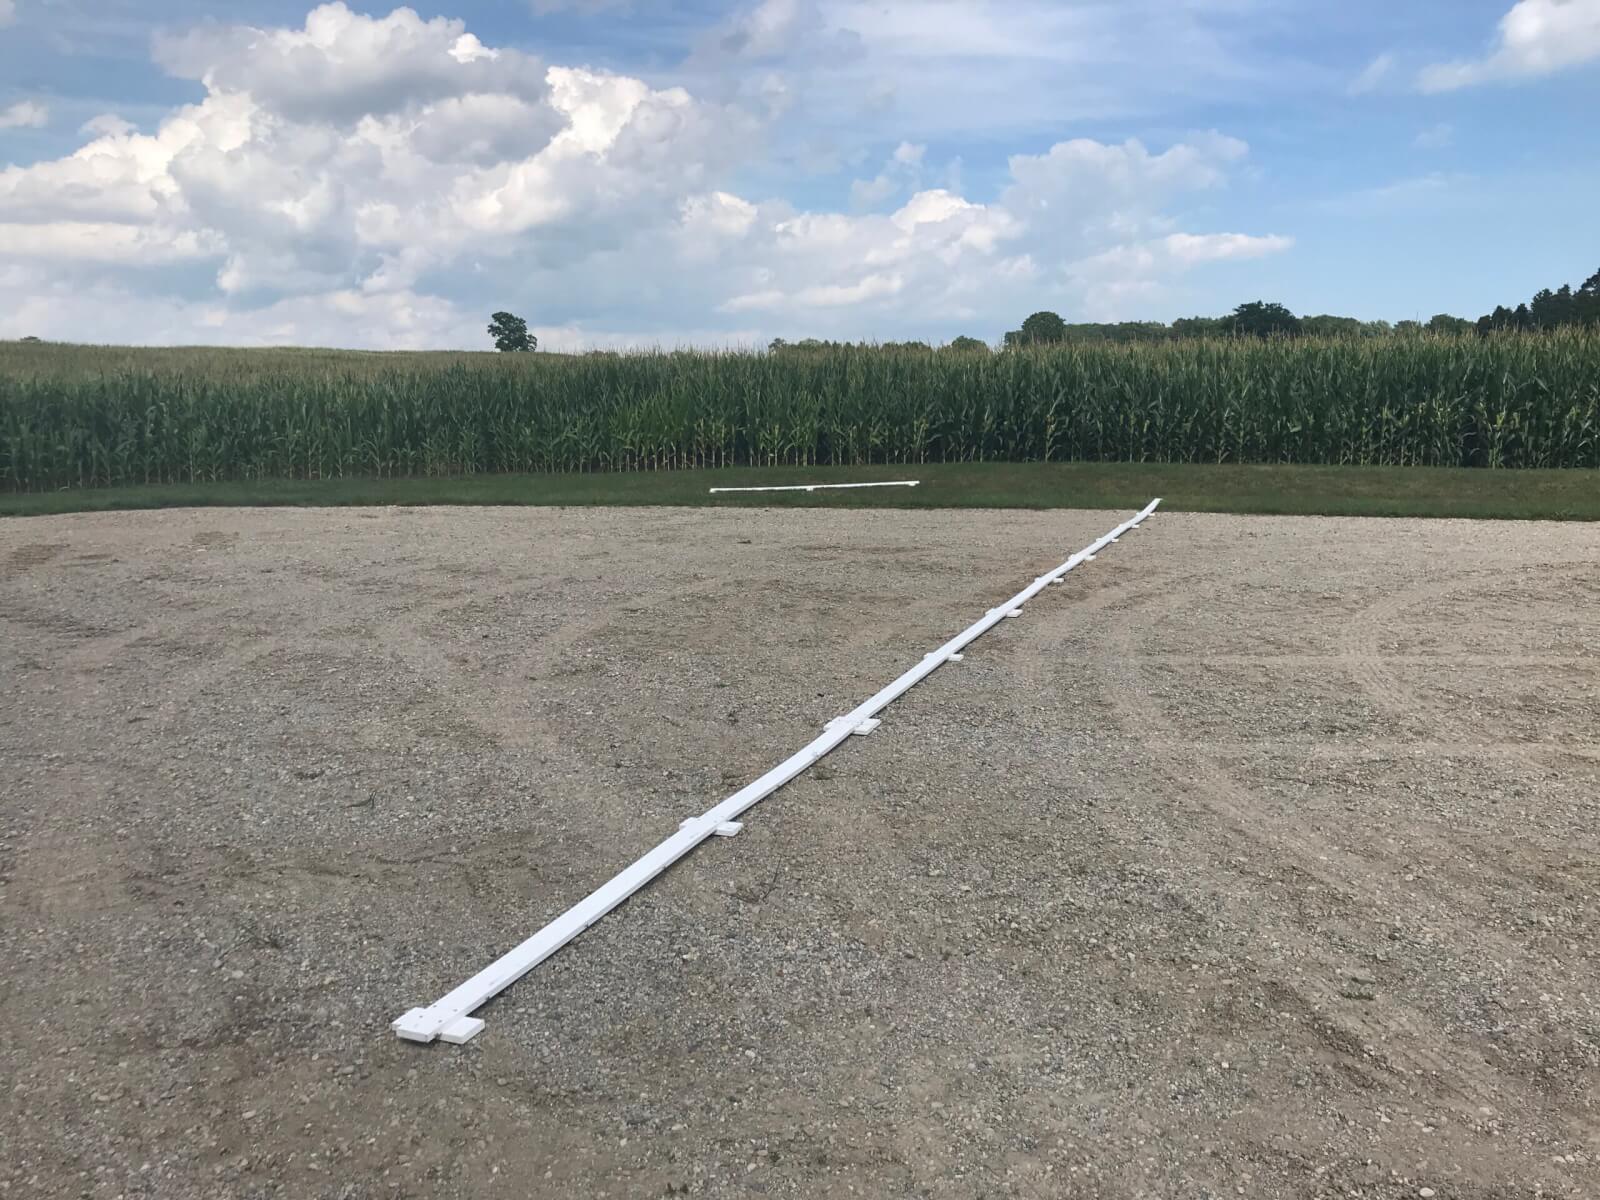
Mark an approximately 200 m long flight line into the prevailing wind direction by placing wire flags every 50 m.
At the 150 m mark, use wire flags to centre a sampler line perpendicular to the flight path. Sampler line length should be about twice the expected swath width.
Swath sampling line
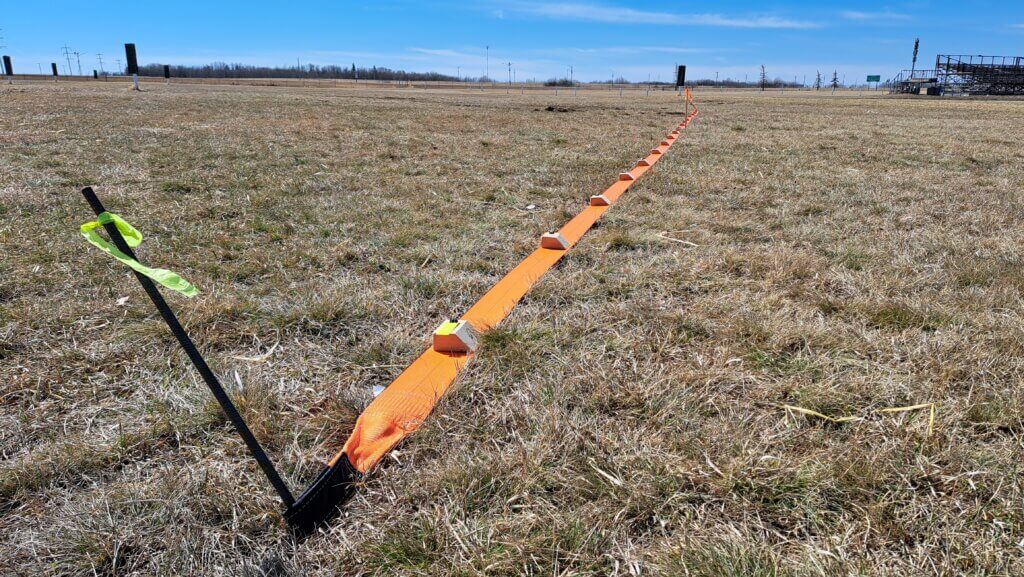
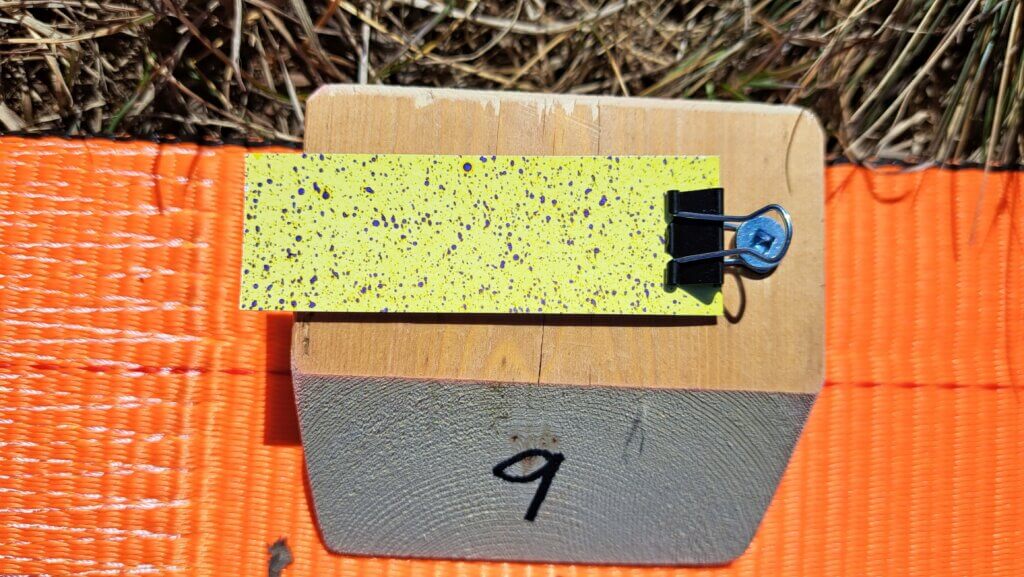
Wooden blocks with paper clips can be used to secure WSP at regular intervals along the sampler line.
Wooden blocks attached to a 4″ tow strap allows for easy setup and movement of sampling line.
Fill the drone 1/2 full.
Manually fly the drone along the entire flight line. The spray pressure, flow rate and altitude of the drone should be stable before it reaches the sampler line. This may take 25 meters or more depending on drone model, flight speed and drone weight.
Fly 50 m past the sampling line without any drone maneuvering to avoid affecting the deposit.
Land the drone and walk along the sampler line.
Note the deposits in the central region. Walk along line as the deposits taper off, looking for deposits that are approximately 50% of the average central deposits.
Water-sensitive paper following a drone application.
Estimate the distance between these deposits on both edges of the swath. This is the estimated swath width that can be entered for the second flight.
Replace the WSP with a fresh set, refill the drone to 1/2 full, and repeat the flight two more times.
Other methods perform a more advanced assessment by analyzing the entire swath, and not just intervals. These methods use dyes and dedicated hardware to quantify the deposits along strings or paper samplers.
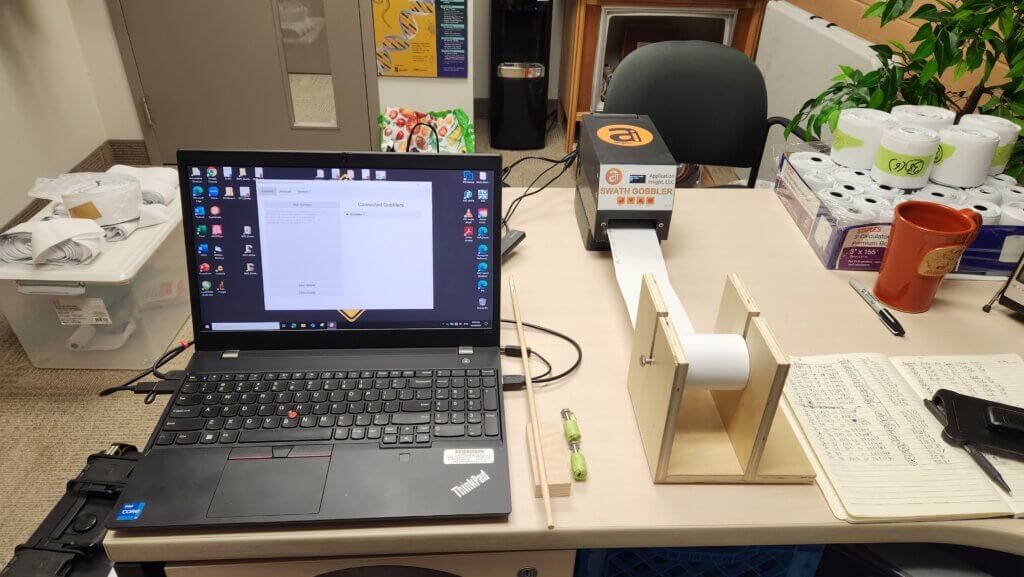
The Swath Gobbler documents swaths at high resolution using lengths of 3″ bonded receipt paper, food grade dye, and a digital scanner.The Application Insight LLC Swath Gobbler scanner in action.
3. Analyze the Pattern
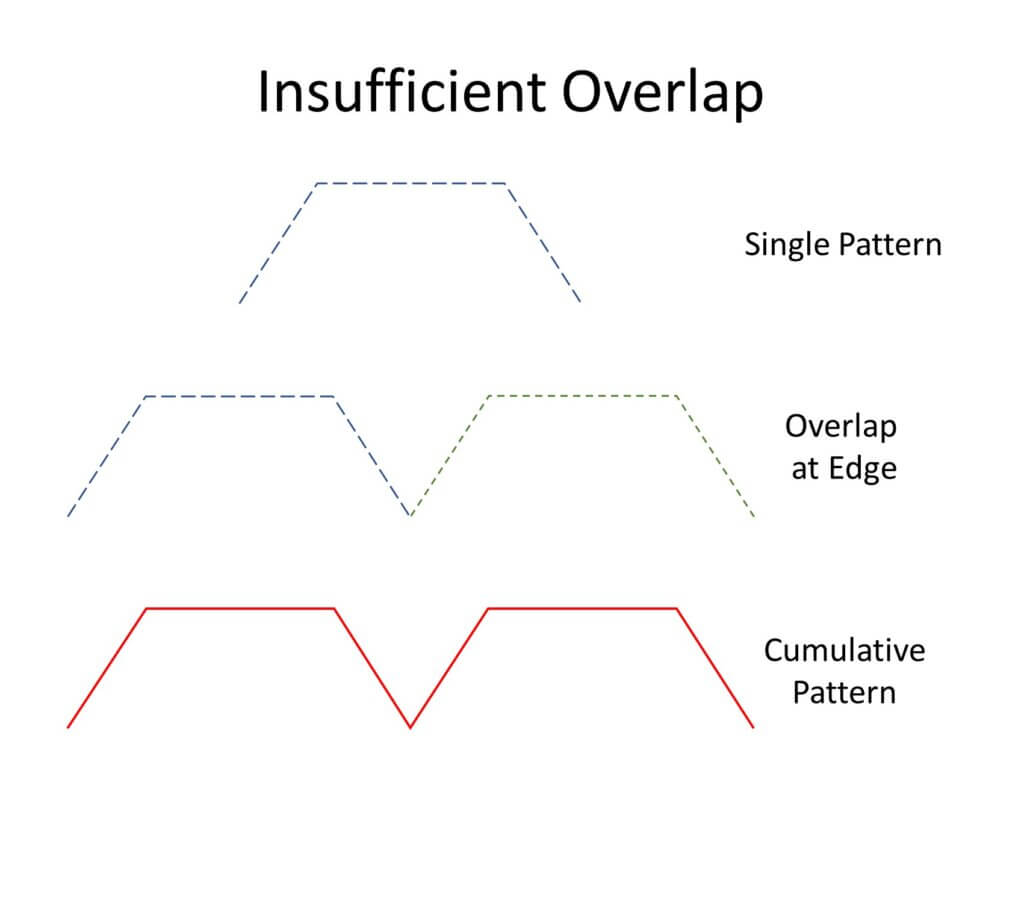
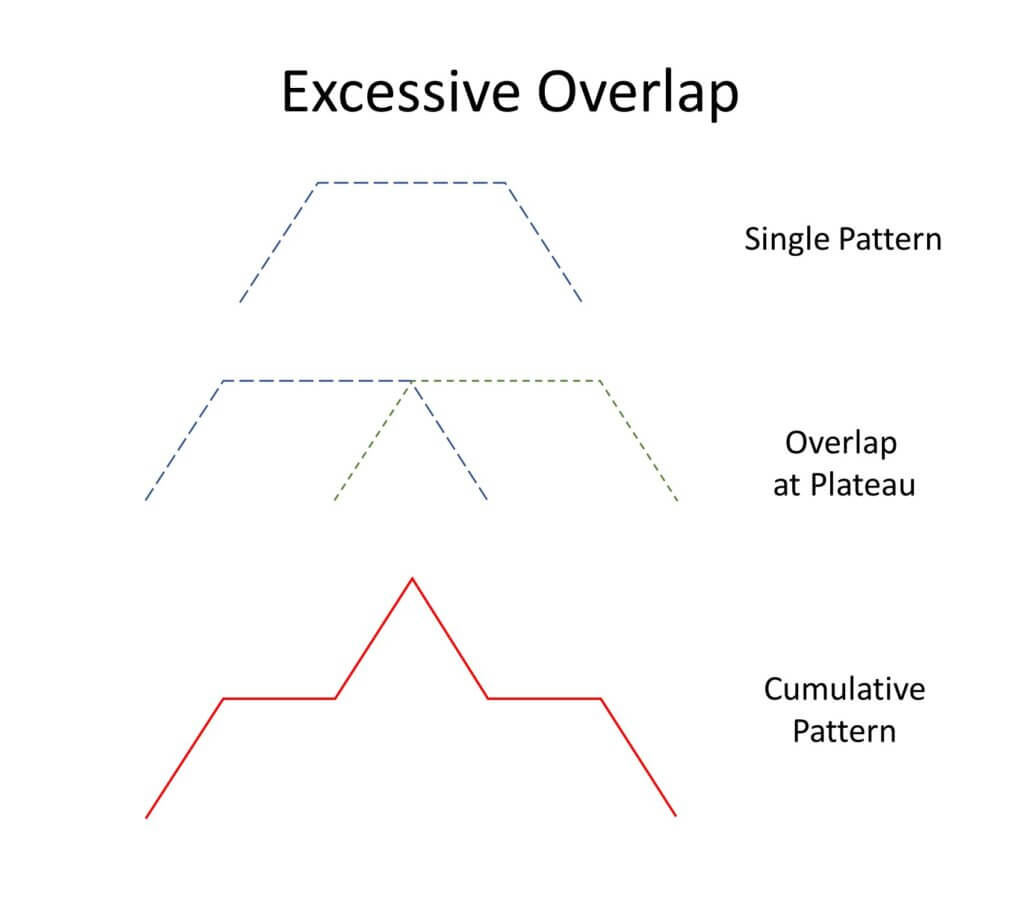
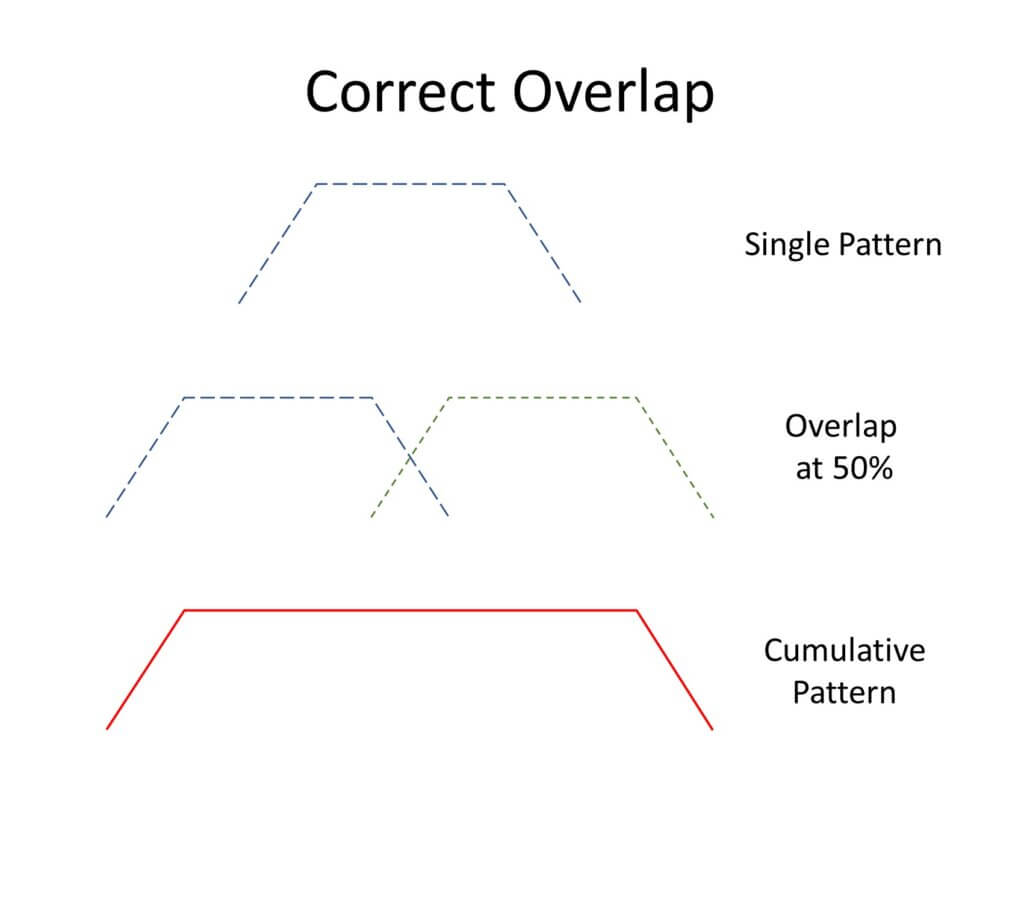
The nearest approximation for drone swathing is that of a manned aircraft. The spray pattern of an aircraft is tapered, meaning the highest deposition is near the centre of the swath, and the edges of the swath fade to zero deposit. In order to achieve consistent coverage, we need the edges of the spray swath to overlap so the cumulative coverage at the edges is closer to that in the centre. Too little overlap leaves gaps and too much overlap results in excessive deposit.
Insufficient overlap creates gaps in coverageExcessive overlap results in over-dosing and wasteCorrect overlap is necessary for efficient and effective application.
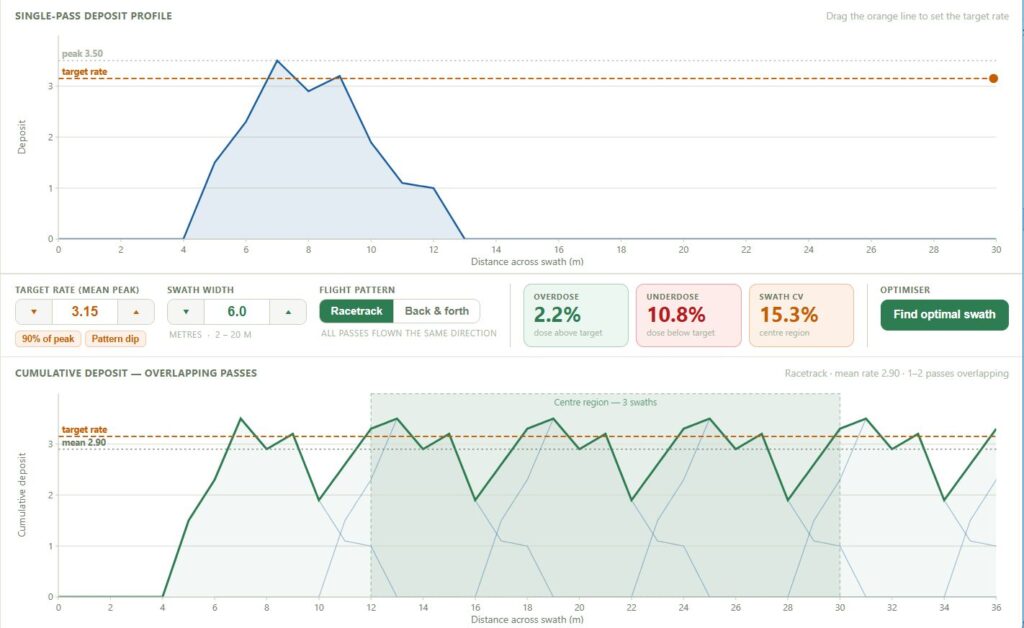
Deposits from drones can be highly variable. The challenge is to find an overlap distance that minimizes this variability, minimizes both over- and under-application, and maximizes swath width. Download a copy of an app we’ve developed to help you with this process.
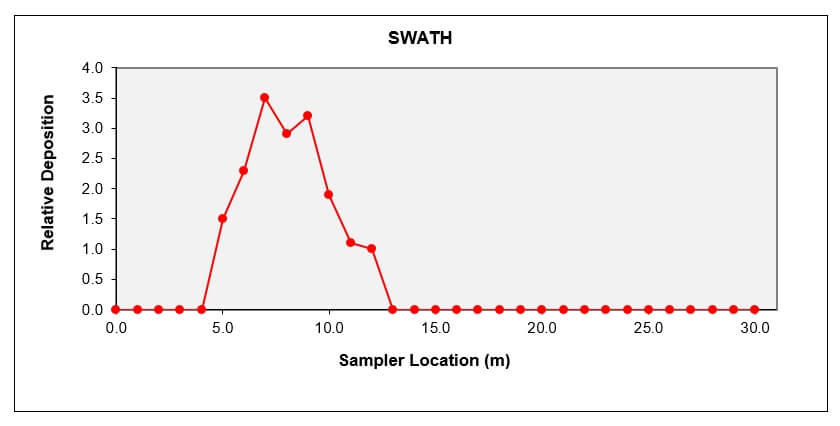
The first step is to estimate a reasonable average deposit, called “Threshold”. The app graphs the deposits from each sampler, and the user estimates a point on the Y axis (Relative Deposition) that represents the average maximum deposit. This could be the maximum value of the plateau, or a midpoint between the maximum and a nearby dip. The app assumes a value that is 90% of the maximum, to start.
We then take 50% of this estimated average deposit, and find the two distances on the X axis (Sampler Locations) that intersect the curve at these points. The distance between these two points is our first estimate of the swath width. If two adjacent swaths are spaced so the edge of one overlaps 50% with the next, the overall cumulative deposit should be relatively even.
The coverage information from each sampler location is graphed to create a deposit pattern.
We can alter the amount of overlap to improve the apparent uniformity, but be cautious. For example, even though we can often improve the uniformity by narrowing the swath width, this can add deposit to the area under the drone and raise the overall deposit amount. That would be waste. Plus, the narrower swath also lowers the productivity of the drone. Use the app to establish a swath width that has the lowest variability (Coefficient of Variability or CV) AND results in a balance between over- and under-dosing. The app has an “Optimize” button that can do this for you.
It’s possible to select a racetrack or a back and forth pattern. We’ve been using the racetrack pattern even though in real life the drone will frly back and forth, for the following reason: We expect a field to be sprayed in a sidewind. The tail of the deposit will always be on the same side of the pattern even with a back and forth flight path. In essence, the wwind creates a racetrack pattern for us.
The amount of overlap is adjusted to minimize variability (CV) and both equalize and minimize over- and under-dosing.
The app allows you to import your data using an Excel file. If the file has multiple data column, the user can select the column to be analyzed. From that point, other columns can be selected as the analysis proceeds. Each analysis can be saved and exported as a pdf file.
4. Recognize the factors that influence swath width
Operational use case affects swath width
Swath width is affected by altitude, speed, water volume and spray quality. Generally, higher altitudes, lower volumes, and finer sprays will result in a wider swath. Unfortunately, the same configuration also results in greater drift. It is recommended that swath widths be determined for each spray volume and nozzle arrangement that will be used.
Drones will be applying low water volumes and this requires a critical assessment of coverage to ensure the deposit density is sufficient to achieve the desired result. A low volume will require a finer spray for minimum coverage to be realized. Coarser sprays that reduce drift and evaporation will need higher water volumes and result in narrower swaths. Significant time may need to be invested to understand the effects of operational settings and environmental conditions on spray deposit uniformity and swath width.
Effective Swath Width and the Agronomic Use Case
The relatively sparse coverage at the extremes of the measured swath width may be insufficient to elicit the desired biological result. The Effective Swath Width (ESW) represents the segment of the total swath width that results in pesticide efficacy. In some use cases, the two widths can be similar, but typically the ESW is only a fraction.
The difference is influenced by the “Agronomic Use Case” which includes factors such as:
Spray mix rheology (i.e. the interaction of spray mix viscosity and atomizer design on droplet size)
Minimum effective dose: This is a complex relationship between coverage, spray mix concentration and pesticide mode-of-action that results in an effective result while minimizing the environmental impact.
Target location (e.g. a pest within a dense canopy or a weed on relatively bare ground)
Taken collectively, research has shown a 20-30% reduction in ESW for corn, wheat and soybean fungicide applications compared to swaths measured on open ground. Conversely, herbicides sprayed on bare earth or sparse vegetation can produce an efficacious response 20% wider than the measured swath width. The impact of agronomic use case on ESW must be considered during mission planning.
Additional pointers
Here are a few tips and tricks to help you be successful when calibrating your drone.
Drone patterns will have deposit peaks and valleys in the central region. Repeated runs are needed to confirm that these are real and persistent. If so, then adjustments in flying height, spray quality, or water volume may be needed to eliminate them.
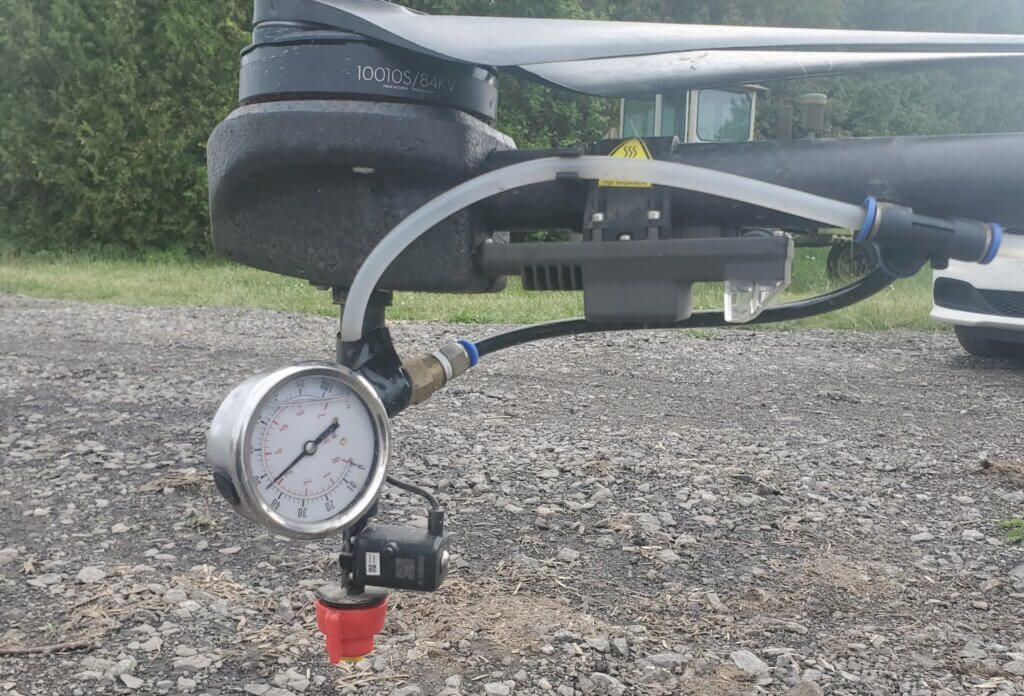
The absence of pressure gauges on drones can be corrected by installing an analog gauge in-line with one of the spray nozzles. If may be necessary to mount an auxiliary camera on the drone to record this gauge. We have observed strong fluctuations in spray pressure, particularly on starting a spray swath, that were not reflected in the reported flow rate.
A pressure gauge can be plumbed into a drone without affecting flight behaviour. A camera is trained on it to read pressure during a flight.
Many drones have the option of recording the flight screen during a mission. This will provide a record of the performance of the drone, and can be valuable should performance problems arise.
Although swath width calibration is done by flying into a headwind, the actual spray application should be done with a side wind. Start at the downwind edge of the field and turn into the wind. The drone is symmetrical and the tapered spray patterns should equalize the deposits. Alternately, flying into a headwind and returning with a tailwind can alter the aerodynamics of the spray deposition process, alternating between a wider and more narrow swath width, respectively.
Drone spraying will walk a razor’s edge of sorts – there is little room for error when using scant water and fine droplets. Getting the basics right has never been more important.
Drone operational settings such as capacity, speed, and swath width are useful figures for calculating productivity, but they only describe the airborne portion of the job. A commercial application business must also transport water, mix product, charge batteries, and establish an efficient staging area that is both safe for operators and maintains drone connectivity. If any of these functions fall behind, productivity suffers.
We consulted several mission records to develop a productivity calculator that can model a range of scenarios. We assumed a shuttle (back-and-forth) flight pattern to apply successive spray swaths for uniform coverage of a treatment area.
How to use
In this, version 4.0 of our drone productivity calculator, we’ve expanded the functionality to include several tendering options. If you are uncertain what the variables mean, consult this handy instruction manual to walk you through the process.
Use it as a planning tool, or simply as a way to explore the impact of different operational settings on mission productivity. We propose adjusting variables one at a time to determine their effect. You can then compound the effect by changing another, or return to the base value and choose another variable to manipulate. In this way you can explore the relative influence of each variable on the overall job.
Which factors matter most?
The relative impact of each operational setting (or the geometry of the target area) on productivity is situation-specific. Nevertheless, here are some generic observations:
While swath width and flight speed play a role, both are limited by the agronomic realities of the job. So, while you can change them in the calculator, it does not follow that the results of the application will be successful.
Water rate (e.g. L/ha) has an impact on productivity, but once again there are agronomic considerations. Too low a volume can compromise product efficacy and contribute to off target drift, and quite often the minimum volume is stipulated on the product label.
The drone’s tank capacity depends on the model, but maxing it out may not be the best option. Some large drones suffer reduced battery life and slower acceleration when filled completely. Note that when the user forces a refill/battery swap, there will be spray mix left in the drone. It is prudent to minimize this residual by not overfilling the drone in the first place.
The ferrying distance between where the drone empties and the staging area a critical productivity factor, so minimizing it is a reasonable objective. Doing so can mean additional sorties, which require additional refills and battery swaps. Small improvements here compound into big impacts, but pay close attention to see if the additional sorties are worth the time savings.
The number of operators have a significant effect on productivity. If a solo operator has to retrieve additional water, or move the tender truck to a new location, the drone isn’t spraying.
Batteries – A potentially limiting factor
The calculator assumes that a sufficiently charged battery is ready whenever the drone returns to the tender, so battery charging does not extend the entered refill and battery-swap time.
In practice, flight endurance can change dramatically with payload. For example, a heavily loaded aircraft may fly for only a few minutes, while the same aircraft may remain airborne much longer with an empty tank. Repeated short, high-load sorties may therefore consume charged batteries faster than they can be recharged.
If the battery inventory, chargers, generator capacity or electrical supply cannot keep pace, the crew may eventually have to wait for batteries, reducing actual productivity below the calculator’s estimate. Additional batteries, higher-capacity charging equipment or improved generator capacity may be required to sustain the projected workflow.
Thanks to Mike Verhoog (Drone Spray Canada) and Dr. Michael Reinke (Michigan State) for discussions contributing to the design of this model.
In this study, 3D sampling of drone spray applications in wheat demonstrates that coverage is strongly influenced by the interaction between drone downwash, flight speed, and wind conditions. These factors collectively determine where droplets land, how evenly they are distributed, and how reliable coverage is from pass to pass. In 2025 we characterized wheat head coverage from a DJI Agras T50. In this study, we explore the larger, faster DJI Agras T100, and relate the observations to what we’ve seen in previous studies.
Materials and Methods
Site and crop
The experiment was conducted at 45939 John Wise Line, St. Thomas, Ontario (42°43’57.0″N, 81°05’49.8″W) on June 3, 2025. Wheat was seeded at 1.8 million seeds/ac on 19 cm spacing and was at the T3 stage (~0.7 m height) at application.
Design
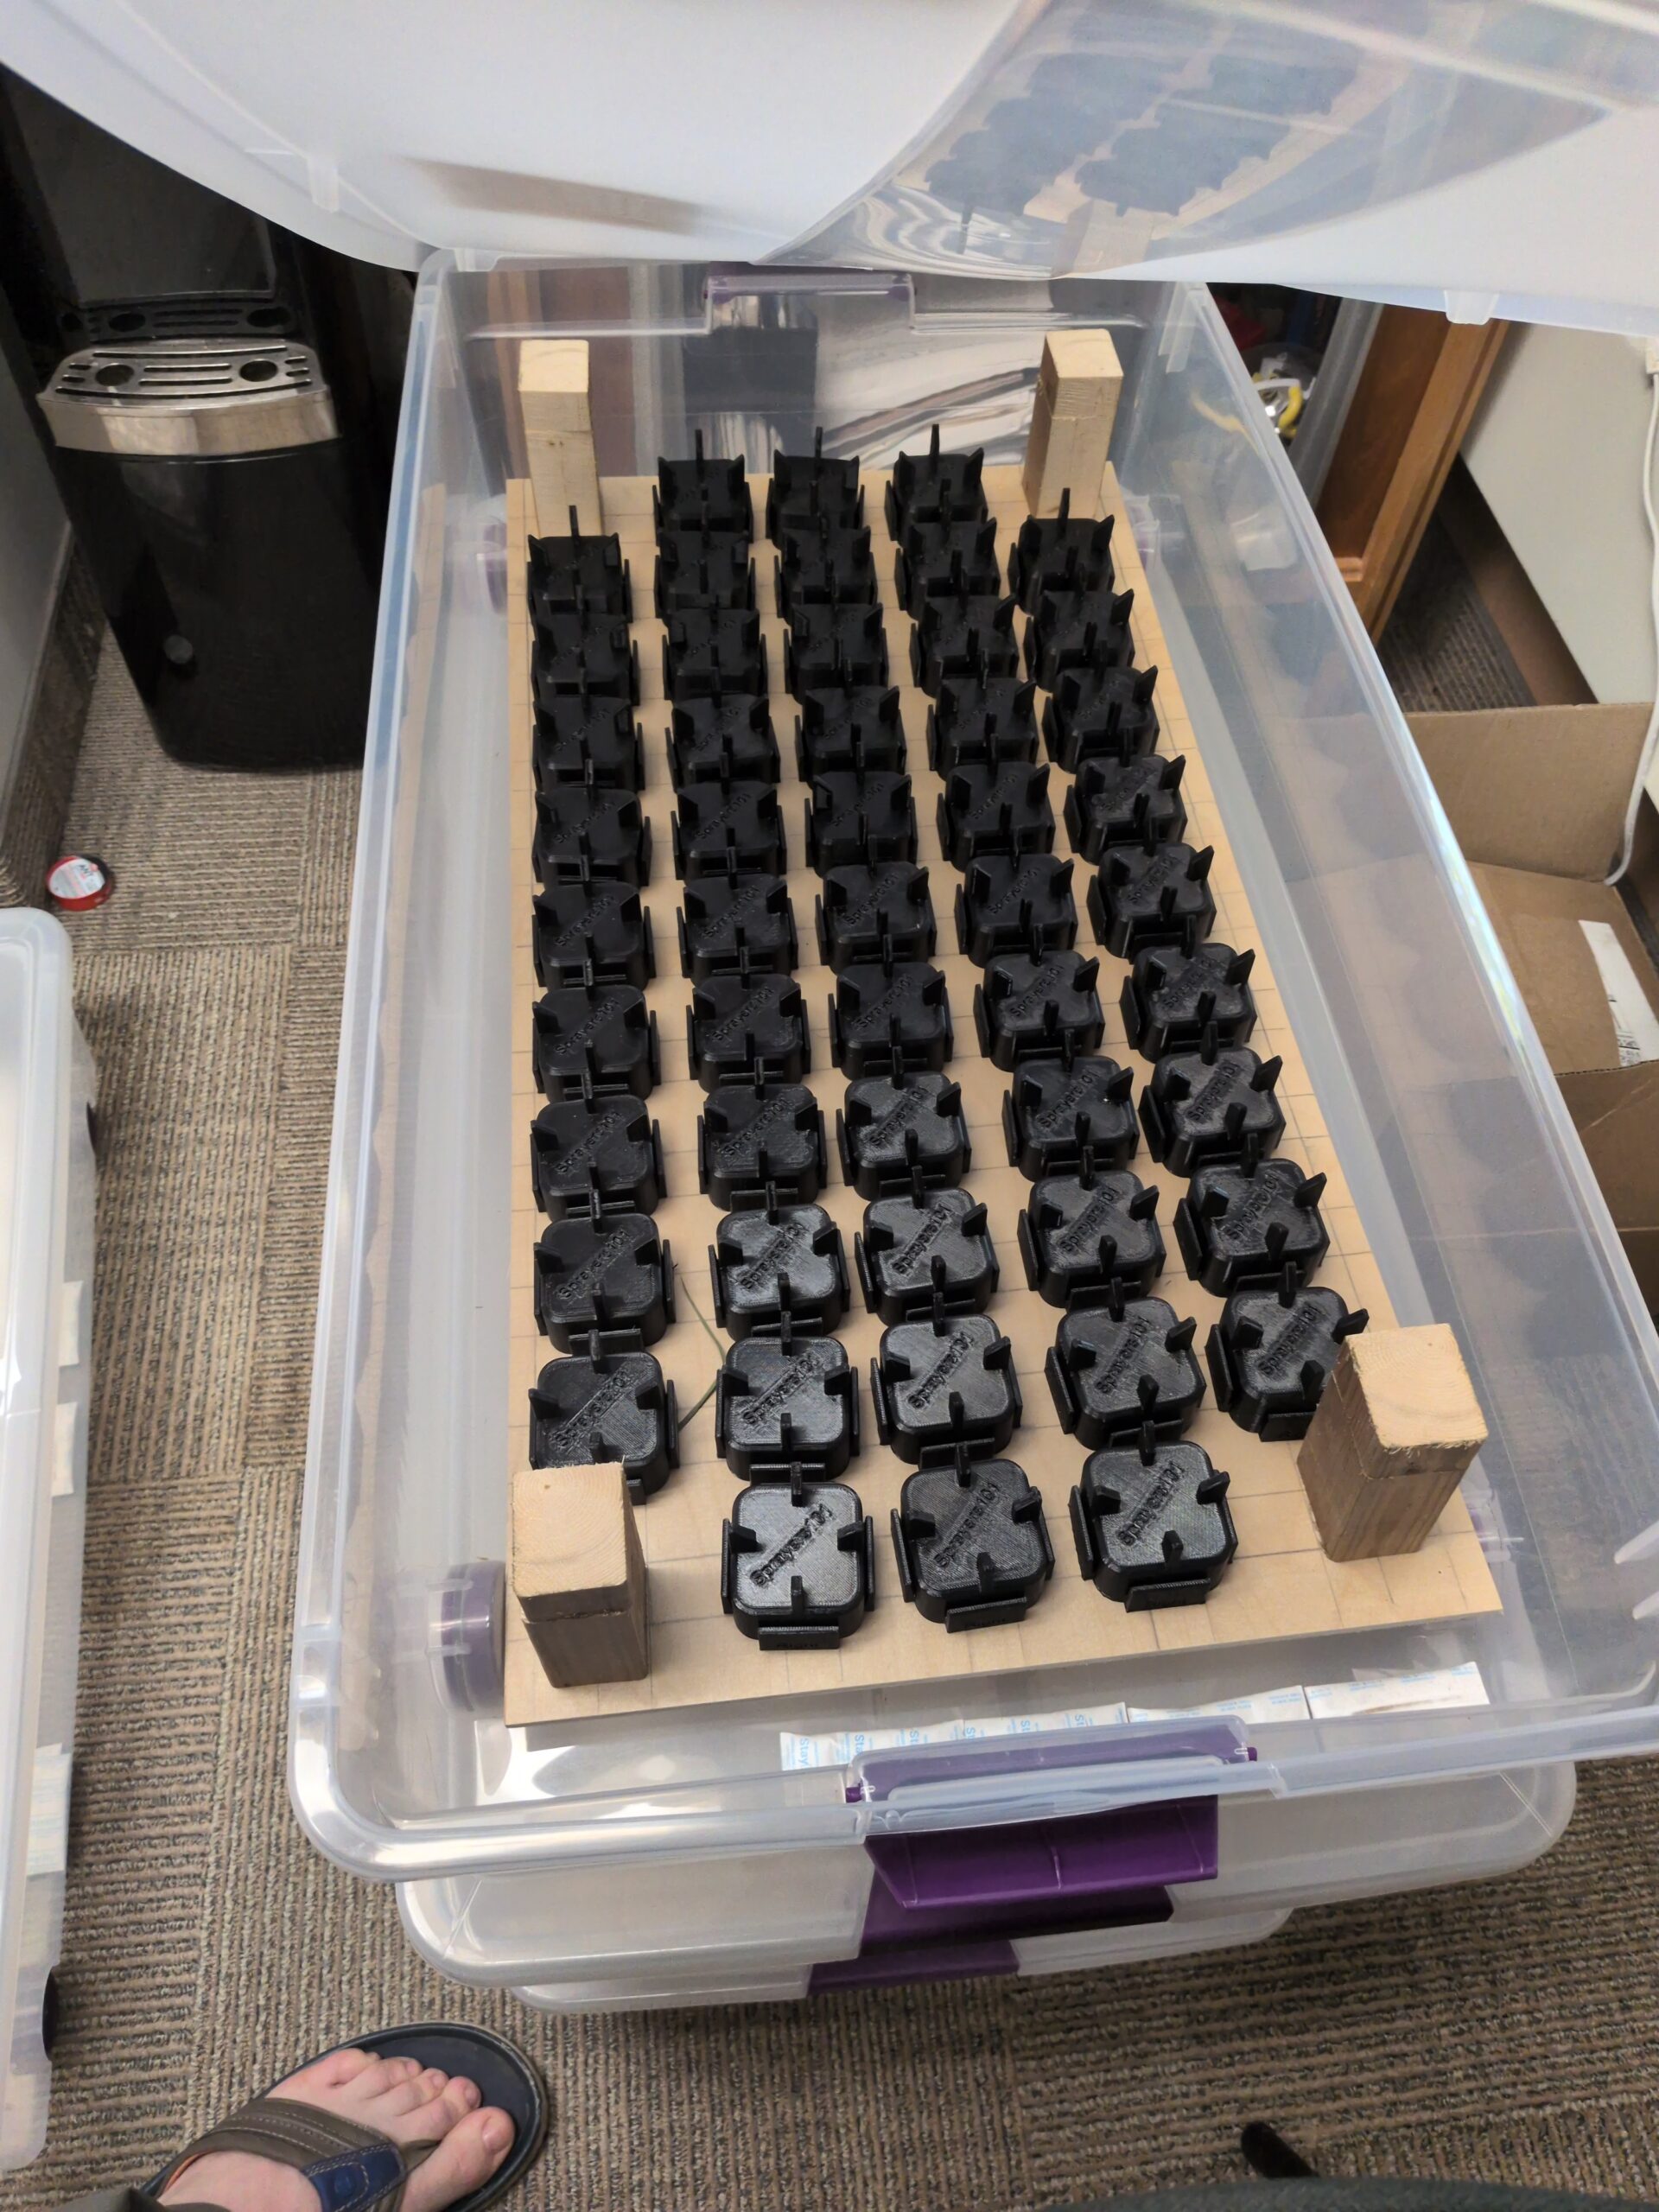
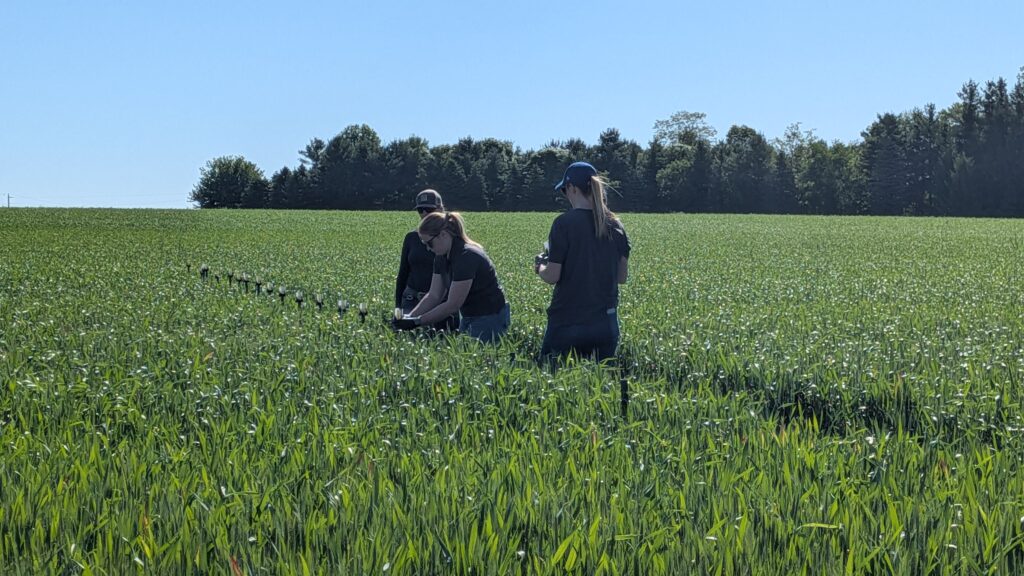
Twenty-one poles spaced at 1 m intervals held 3D-printed mounts with 1×3″ water-sensitive papers oriented in four directions relative to the drone flight path: advance, retreat, left, and right. A tramline behind the array preserved canopy structure while allowing access to the samplers (Figure 1).
Figure 1 – Volunteers retrieving and replacing samplers between passes.
Drone Operational Settings
The primary objective of the study was to explore the effect of flight speed on coverage. Speed was increased from 6, to 10, to 14 m/s with the following operational settings:
4 LX07550SX (sprinkler) nozzles
50 L/ha application volume
350 µm droplet size
4 m flight altitude
7 m programmed swath width
Tank volume maintained at ~50 L
The drone began spraying 50 m before and continued 20 m after the samplers, flown on full auto over pole 10 and 11 (the middle of the 21 poles). The spray liquid was municipal water with 0.5% v/v of MasterLock (Winfield United).
The secondary objective was to compare coverage from the drone spraying 5 gpa (6 m/s) to a 10 gpa (7 m/s) condition.
Weather
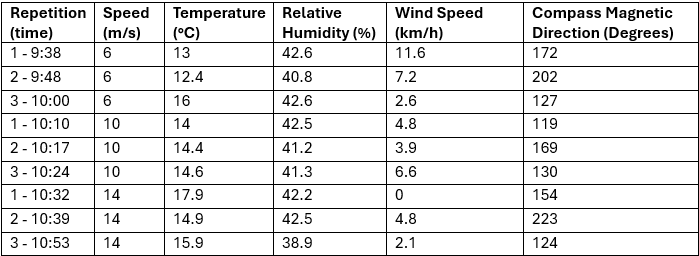
Weather data was collected using a Kestrel 3550AG weather meter (Kestrel Instruments) in a vane mount positioned roughly 2 m below drone altitude. Data was logged as the drone passed the samplers (Table 1).
Table 1 – Weather conditions for each spray pass.
Flights were conducted under a prevailing tailwind (rather than the preferred headwind) due to field constraints. Wind conditions during application varied by treatment. The 6 m/s treatment experienced higher and more variable wind speeds (avg. 6.6 km/h, SD 3.7 km/h, 177°), predominantly from the north (tailwind). The 10 m/s treatment occurred under moderate and stable winds (avg. 4.8 km/h, SD 1.1 km/h, 136°) with a slight right-to-left crosswind component. The 14 m/s treatment experienced low and variable wind speeds (avg. 1.6 km/h, SD 2.0 km/h, 198°) including periods of calm .
Results
Deposition Magnitude and Orientation
Papers were analyzed using a DropScope™ (SprayX, São Carlos, Brazil). Deposition differed strongly by collector orientation (Table 2). Some repetitions were removed if wind pushed spray beyond the collectors. This left a minimum 2 repetitions per condition.
Speed
Direction
Mean(deposits/cm2)
Std Dev
Min
Max
6 m/s
Advance
45.70
67.03
1.3
210.7
Left
40.06
66.19
0.0
211.8
Retreat
20.10
20.25
0.0
71.0
Right
45.47
73.55
0.0
208.9
10 m/s
Advance
52.07
63.05
0.1
189.3
Left
31.95
43.65
0.0
136.0
Retreat
5.12
9.19
0.0
37.6
Right
37.22
70.18
0.0
202.1
14 m/s
Advance
39.02
37.51
0.5
115.3
Left
26.89
43.91
0.0
130.9
Retreat
0.43
1.27
0.0
5.7
Right
11.03
22.53
0.0
71.2
Table 2 – Average deposition by sampler orientation for each speed.
Forward-facing collectors (advance) consistently recorded the highest deposition across all speeds, followed by lateral orientations. Reverse-facing collectors (retreat) recorded substantially lower deposition. Variability was high for advance and lateral orientations, whereas retreat collectors showed consistently low variability (Table 3).
Direction
Mean(deposits/cm2)
Std Dev
Min
Max
Advance
39.02
37.51
0.5
115.3
Left
26.89
43.91
0.0
130.9
Retreat
0.43
1.27
0.0
5.7
Right
11.03
22.53
0.0
71.2
Table 3 – Average deposition by sampler orientation for all passes.
Directional Bias (Anisotropy)
Anisotropy refers to the property of having different values when measured in different directions. We can quantify this by dividing the average coverage on one plane by the opposite plane; The resulting indices show the relative direction of deposition.
For the lateral plane (left-to-right), we divide the average coverage on the left-facing orientation by the right. On the sagittal plane (advance-to-retreat), we divide the average coverage on the advance-facing orientation by the retreat (Table 4).
Speed
Lateral (L÷R)
Sagittal (A÷R)
6 m/s
0.88 (slight right-dominant)
2.27 (moderate advance-dominant)
10 m/s
0.86 (slight right-dominant)
10.17 (strong advance-dominant)
14 m/s
2.44 (strong left-dominant)
90.05 (almost entirely advance-dominant)
Table 4 – Relative coverage indices for lateral and sagittal planes.
Bias in the lateral index was relatively weak, with a subtle shift with the wind (wind-facing is left) at higher speeds. The sagittal index (advance-to-retreat) increased from a 2x between 6 m/s and 10 m/s to 5x between 10 m/s and 14 m/s, demonstrating strong forward bias with flight and wind direction despite the down-and-back vector created by the downwash.
Spatial Distribution
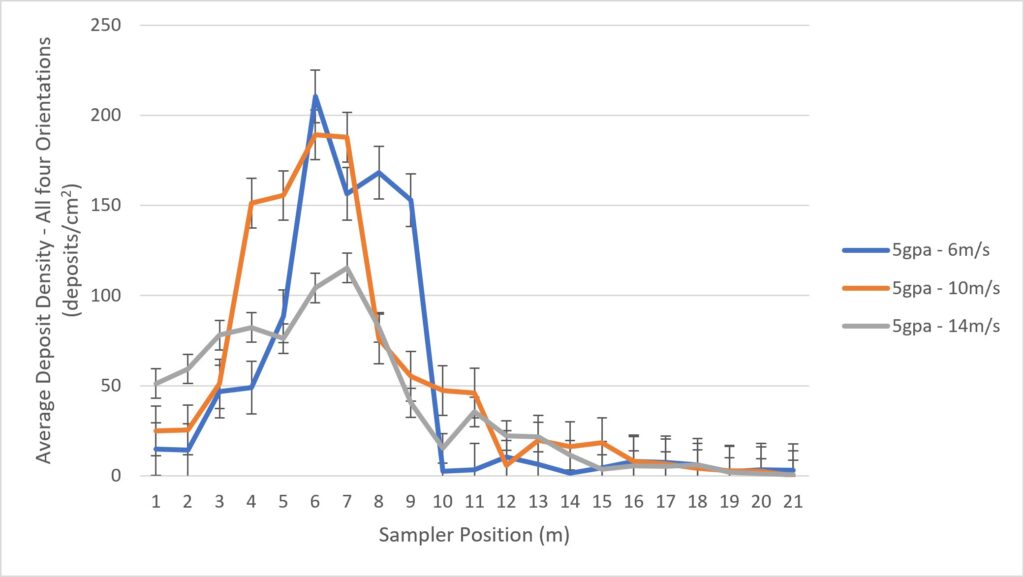
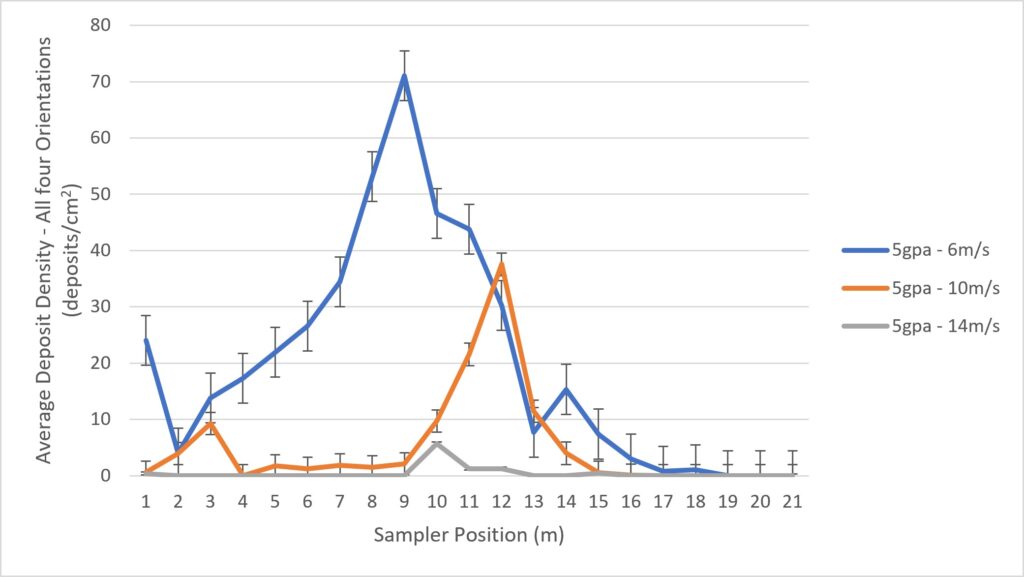
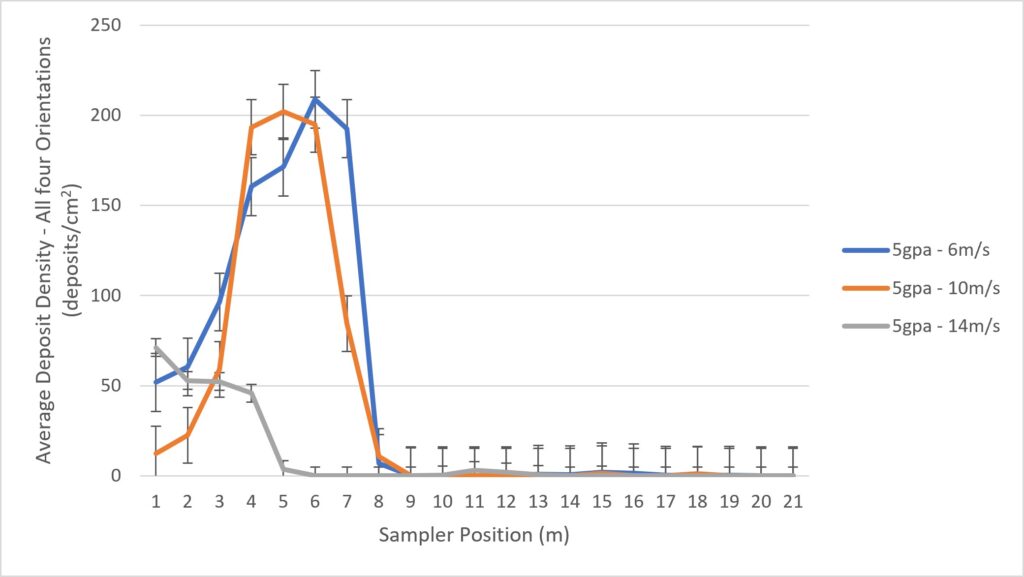
Peak deposition consistently occurred 1 to 5 m downwind of the flight line, rather than directly beneath it. A cross-tail wind shifted deposition laterally, while forward motion (inertia) and wind reinforced deposition in the advance direction. This can be illustrated by isolating the average coverage for each orientation, for all three speeds (Figures 2 to 5).
Figure 2- Advance Orientation (Facing tailwind). Bars = SEFigure 3 – Retreat Orientation (facing away from tailwind). Bars = SEFigure 4 – Right Orientation (Facing cross wind). Bars = SEFigure 5 – Left Orientation (facing away from cross wind). Bars = SE
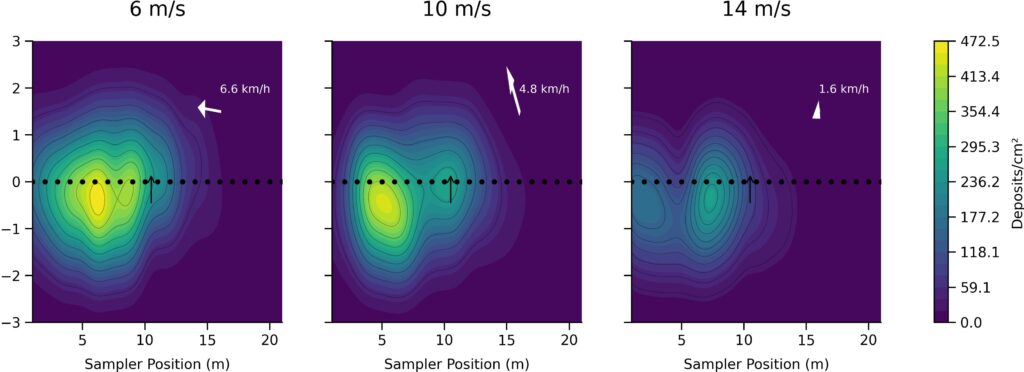
By combining and plotting average coverage on all orientations in a top-down heatmap, we can clearly see the lateral shift to the left of the flight pass (with the light crosswind), the higher relative coverage on the advance face, and indications of bi-modal coverage that likely corresponds to the position of the rotary atomizers(Figure 6).
Figure 6 – Coverage heatmap created by smoothing the average deposition data for each speed (σ ≈ 1.1 – 1.2 m) over a 300 x 300 grid to illustrate deposition gradients. The colour scale supports a direct comparison of deposition intensity. The 21 samplers are indicated by black dots spaced at 1 m intervals, and the drone flight path appears as a black arrow between posts 10 and 11. Average wind speed and direction appears as an inset white arrow (vector).
Effect of flight speed on swath width
Swath width was determined by averaging all deposition on each post for each speed and using our online swath width calculator. The range of flight speeds used in this study did not significantly affect swath width.
6 m/s: 8 m swath width (16.3 % C.V.).
10 m/s: 7.5 m swath width (22.5 % C.V.)
14 m/s: 7.5 m swath width (22.3 % C.V.)
These widths are 15-20% wider than the widths calculated in the same manner during the 2025 study with the T50.
Averaging swath widths can mask variability
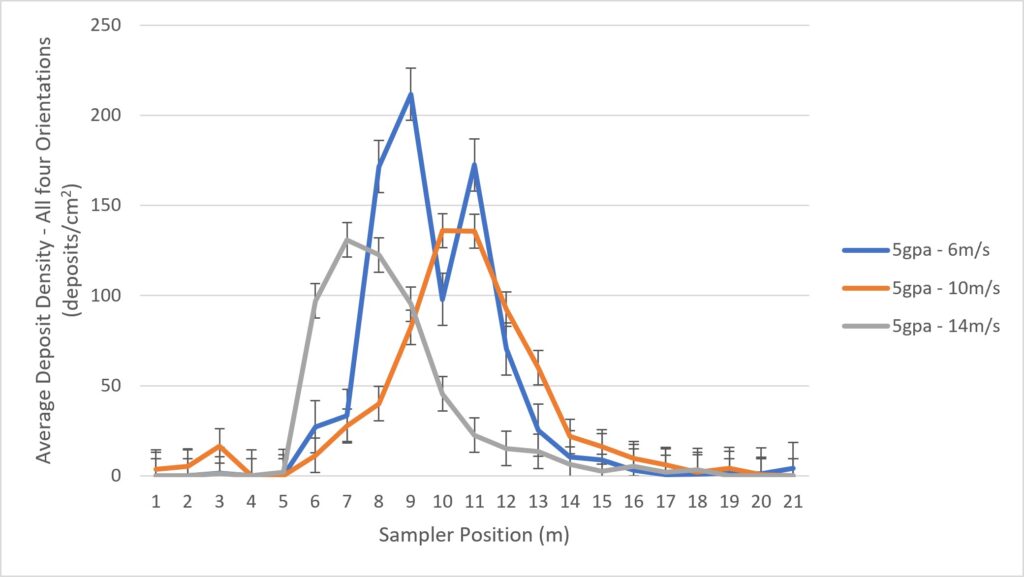
This method of calculating and comparing average swath widths is convenient, but it hides any variability in the amount of spray deposited within the swath. Consider that an 8 m swath with 10 deposits/cm2 every meter would have the same C.V. as an 8 m swath with 100 deposits/cm2. Deposit variability can be illustrated by plotting the average coverage along the swath with standard error (figure 7). We see that flight speed significantly influenced the degree of deposition, where higher speeds reduced the average droplet density (counts) as well as the variability (standard deviation).
Figure 7 – Average coverage, all orientations, for each speed. Bars = SE
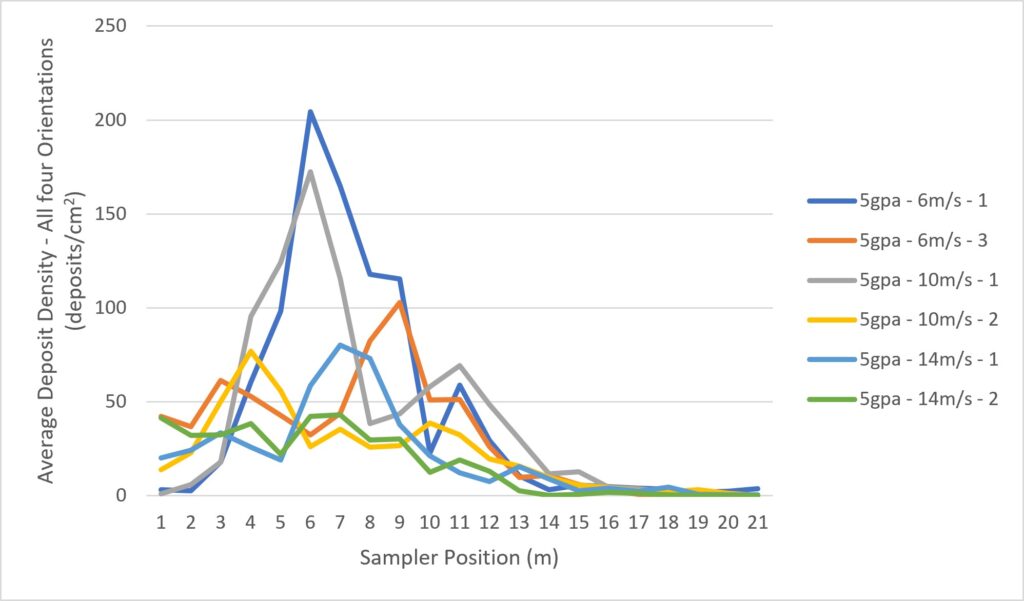
Think of each repetition as a randomly-selected cross section of the swath from somewhere along a spray pass. Calculating swath width from averaged coverage data can hide shifts in the relative position along the flight path, making the composite value greater than that of any single replicate. This variability and the potential for inadvertent smoothing can be exposed by plotting each repetition. (Figure 8).
Figure 7 – Average coverage (all orientations) from each pole plotted by speed and repetition.
Therefore, the order of operations matters. When swath width is calculated for each repetition, and then averaged, we would expect the widths to be somewhat smaller. They are presented here in table form next to the previous values for comparison (Table 5).
Speed (m/s)
(A) Deposition averaged, then swath calculated (m)
(B) Swaths calculated, then average (m)
Difference (A-B) (m)
6
8 (16.3% C.V.)
6 (29.6% C.V.)
-2
10
7.5 (22.5% C.V.)
6 (33.5% C.V.)
-1.5
15
7.5 (22.3% C.V.)
7.5 (30.5% C.V.)
0
Table 5. Average swath widths generated by two methods.
Statistical Analysis
No matter the method, we can draw conclusions from the swath widths calculated here.
6 m/s: highest deposition but greatest variability.
10 m/s: best balance of deposition, uniformity, and swath width.
14 m/s: lowest deposition and most directional bias.
A two-way analysis of variance (ANOVA) was conducted to evaluate the effects of flight speed and collector orientation on spray deposition. Deposition differed significantly between Advance, Left, Right, and Retreat collectors (F = 6.1, p = 0.0005). Flight speed had a statistically significant effect on deposition, where deposition was reduced with speed (F = 3.03, p = 0.05). The effect of orientation did not significantly depend on speed (F = 0.46, p = 0.83), suggesting that the pattern of deposition was consistent across speeds.
Effect of volume on deposition
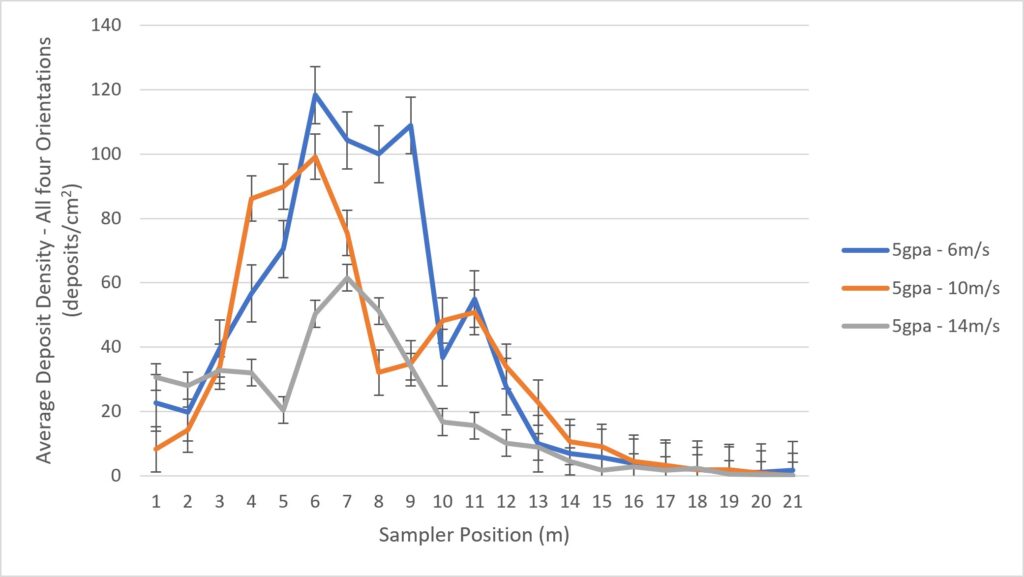
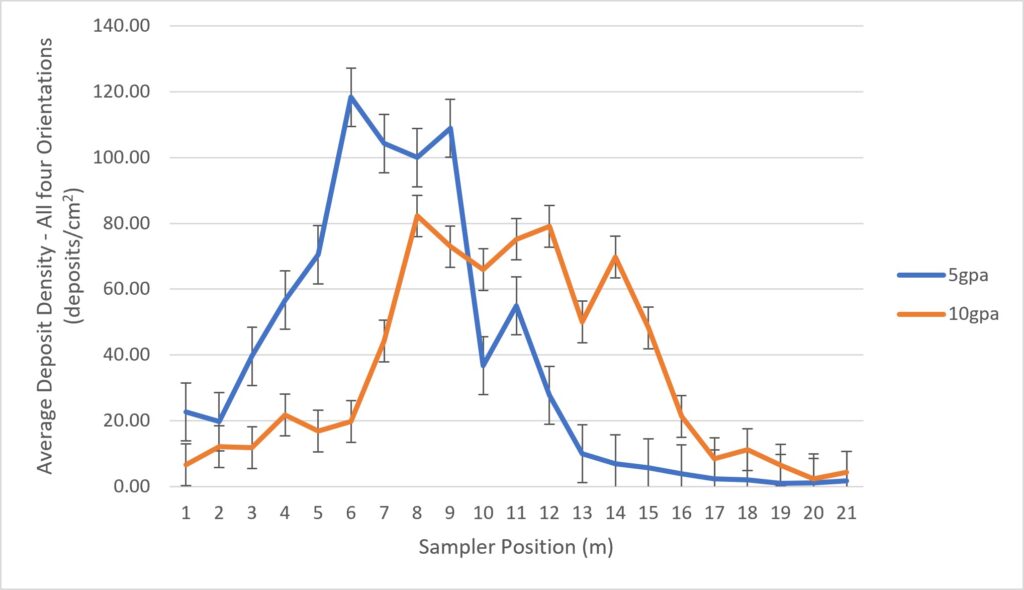
In a secondary investigation, the drone was flown at 7 m/s, applying 10 gpa to compare coverage to the 6 m/s, 5 gpa condition (Figure 8).
Figure 8 – Average coverage as deposit counts, all orientations, for 5 gpa and 10 gpa. n=2 for each condition . Bars = SE
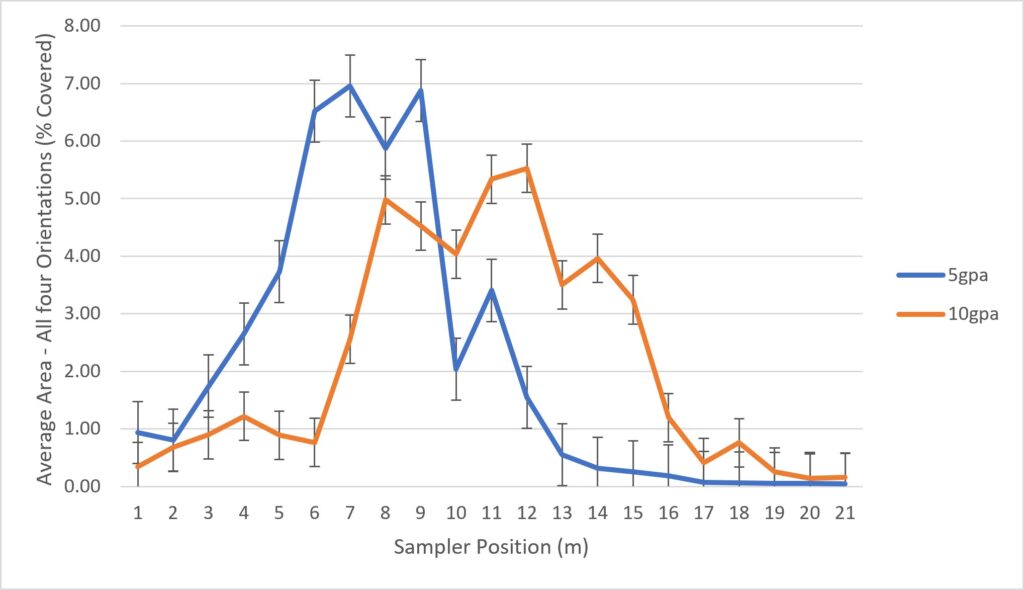
Surprisingly, there was no significant increase in total deposition within the swath when volumes were increased. In fact, the 5 gpa condition is ~8% higher when all deposits are summed or when area under the curve is calculated. The relative shape of the curve was notably different with 5 gpa producing a sharper, higher-intensity central peak, while 10 gpa produced a broader and more uniform deposition profile.
It was expected that higher volumes would result in higher counts. One theory for the absence of this result was that overlapping depositions in the high volume treatment might have underestimated counts when the papers were digitized. Therefore, the percent surface area was also analyzed (Figure 9). Once again, there was no significant difference in the total percent area or a comparison of area under the curves.
Figure 9 – Average coverage as area covered, all orientations, for 5 gpa and 10 gpa. n=2 for each condition . Bars = SE
When swath widths were calculated for each repetition, then averaged for each speed, we arrived at (5 m + 7 m) ÷ 2 = 6 m for the 5 gpa condition, and (5.5 m + 6.5 m) ÷ 2 = 6 m for the 10 gpa condition. We have no explanation for why there was no volume-related difference.
Discussion
Wind direction strongly influenced deposition, overriding the down-and-back pattern seen in previous studies. A tail-cross wind likely drove deposition (likely occurring after the drone passed the sampling location), explaining why retreat-facing collectors captured minimal deposition, and peak deposition was accordingly displaced from the flight line.
Overall, results confirm that wind conditions fundamentally reshape spray distribution. The implication is that wind direction must be accounted for alongside swath width when developing flight path spacing to minimize the potential for overlaps and gaps between passes.
Further, previous studies have demonstrated a direct and positive relationship between flight speed and swath width up to 8-10 m/s with no further response after ~8 m/s. This study supports the hypothesis that rotary-wing drone speed and swath width share an asymptotic relationship that inflects at ~8-10 m/s (variability makes it difficult to determine an exact value). Flight speed also has a direct and inverse impact on the degree of spray deposition and deposit variability within the swath.
Finally, caution is advised when interpreting average swath widths. There may be no indication of the degree of coverage within the swath (affecting efficacy), or the lateral variability along the flight path (affecting fieldwide uniformity).
Related video
Thanks to Adam Pfeffer and Bayer Canada for in kind and financial support, and thanks to volunteers Erin Jewson (OMAFA Engineer), Halle Barton and Nikki Intranuovo (Bayer Summer Students) for their help with the field work.
Author’s Note: These results were adjusted in July to exclude outliers and include the results of the spray volume comparison.
Swath width is a fundamental parameter in spray drone mission planning. It facilitates the uniform application of broadacre pesticides at the target rate. Pilots adjust the swath width via operational settings such as droplet size, flight speed and altitude to produce the most effective and efficient application.
Rapid advances in drone design, however, may warrant a re-evaluation of how operational settings affect swath width. For example, the most recent generation of drones are now capable of speeds up to 20 m/s (72 km/h), which is twice that of the previous generation.
In late 2025 we conducted a series of comparative herbicide applications using the DJI Agras T50 and T100. For both drones, swath width increased with speed up to ~10 m/s, as expected. However, between ~10 m/s and 18.5 m/s, swath width from the T100 did not seem to increase further. Similar observations have been reported by researchers at AgroEfetiva (São Paulo, Brazil; personal communication).
These results suggest that the relationship between speed and swath width is positive and direct at lower speeds, but reaches a saturation point beyond which any further increase in speed no longer affects swath width. This is an asymptotic relationship. To test this hypothesis, we conducted a deposition study where swath width was measured at flight speeds that increased incrementally from 8 m/s to 20 m/s.
Configuration Study
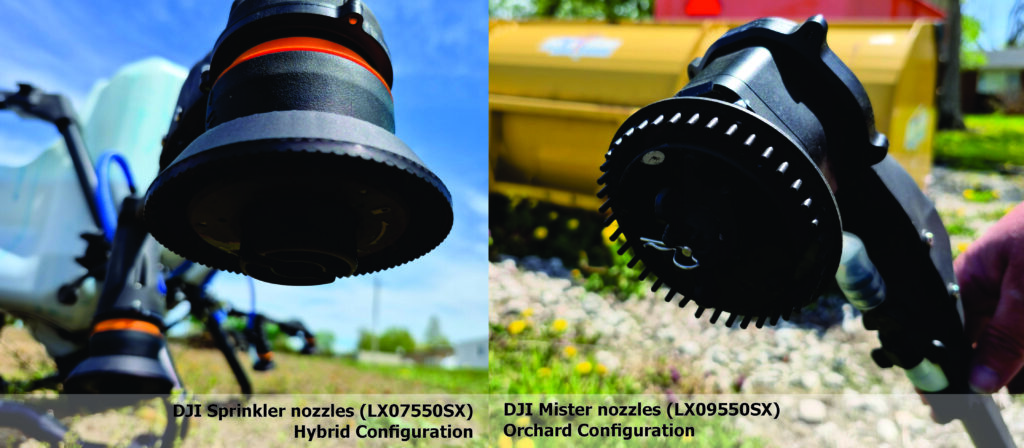
The standard T100 configuration uses two rotary atomizers (“sprinkler” nozzles; LX07550SX) with a reported maximum combined flow rate of 30 L/min. The alternate orchard configuration incorporates a boom that supports two additional “mister” nozzles (LX09550SX), increasing the reported maximum flow rate to 40 L/min.
To improve productivity in broadacre applications, some operators have adopted a hybrid configuration. In this setup, the orchard boom is retained, but the reputedly drift-prone mister nozzles are replaced with a second set of sprinklers. This approach is intended to achieve a higher flow rate than the standard two nozzle configuration while maintaining a larger mean droplet size.
A secondary objective of this study was to compare the Hybrid configuration with the Orchard configuration (Figure 1).
Figure 1 – Left: DJI Sprinkler Nozzle (LX07550SX). Four such nozzles comprised the “Hybrid” configuration. Right: DJI Mister nozzle (LX09550SX). Four such nozzles comprised the “Orchard” configuration.
Materials and Methods
Location and Layout
The study was conducted at Ontario’s Simcoe Research Station on May 12, 2026. The site (42.857414, -80.271759) was a flat, recently tilled sand/loam field with no vegetation present. A DJI Agris T100 drone was used to perform the spray applications, supported by the D-RTK 3 relay station and flown on full auto.
The spray mix was 0.2% v/v Super Signal Blue (Precision Laboratories) and 0.125% v/v Activate Plus NIS (Winfield United) in municipal water, pre-mixed to ensure consistency. A volume of 40 L – 60 L was maintained throughout the trial to minimize the effect of a changing payload.
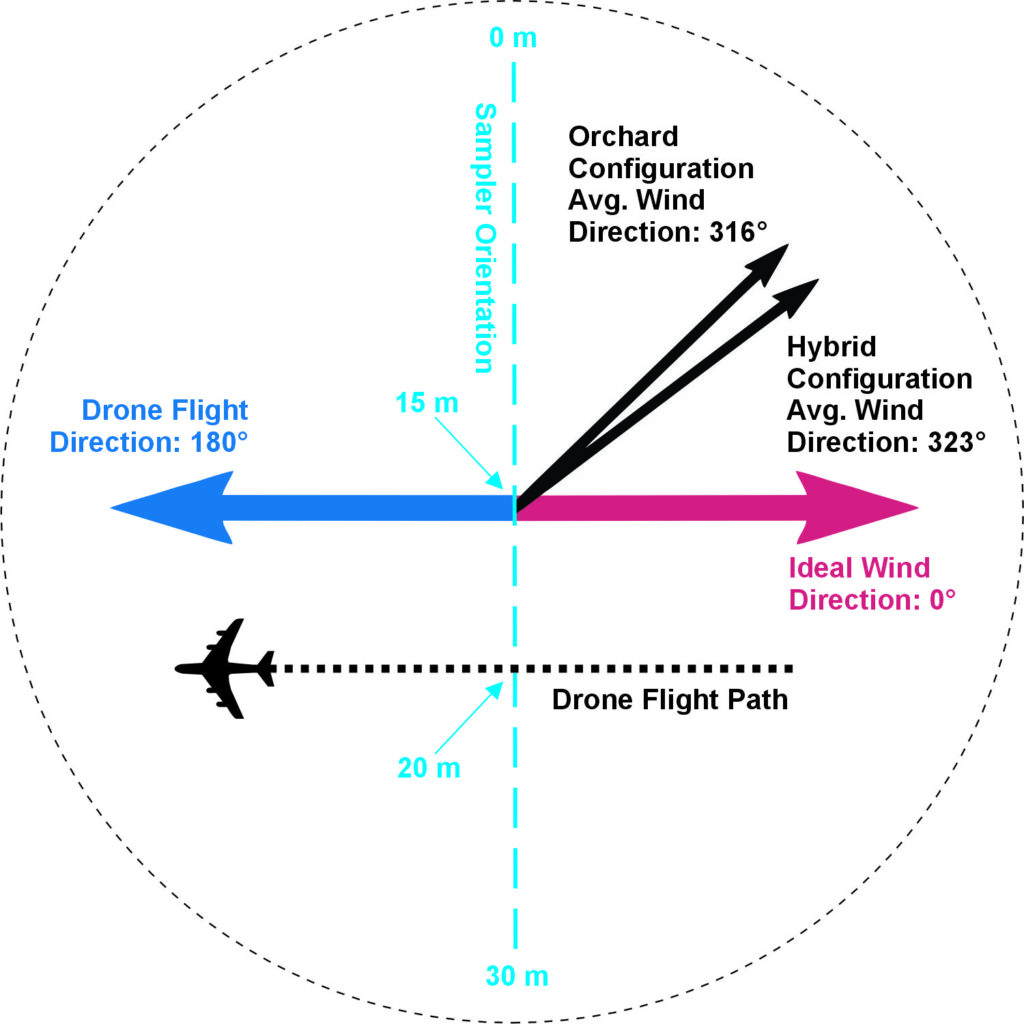
The sampler was a flat, horizontal, continuous bond paper strip measuring 7.5 cm wide and 30 m long (secured in Speed Tracks™, Application Insight LLC). The sampler was oriented perpendicular to the prevailing wind, with the intention of flying the drone with a headwind across the 15 m mark (the centre) (Figure 2). Test passes determined that the T100 required 210 m to reach 20 m/s while half-full.
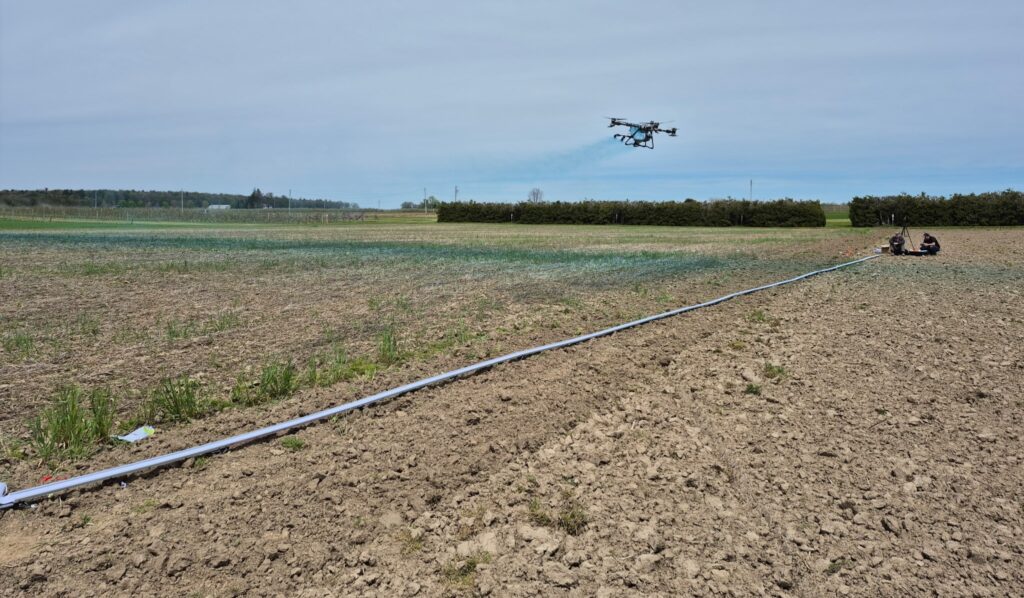
Figure 2 – T100 spraying indicator dye across the 30 m continuous sampler.
Before the swathing runs began, the prevailing wind shifted direction slightly. It was decided to fly the drone 5 m upwind (at the 20 m mark along the 30 m sampler) to ensure any downwind displacement was captured on the sampler (Figure 3).
Figure 3 – Trial layout and prevailing wind conditions.
Drone Settings and Swathing Order
The primary objective of the study was to explore the effect of flight speed on swath width. Speed was increased from 8 m/s to the maximum 20 m/s by 2 m/s increments. Trial and error with the controller indicated that we could achieve these speeds by balancing an application volume of 30 L/ha and a programmed swath width of 7 m.
Altitude was set to 4 m which is lower than the 5 m minimum recommended by DJI for high-speed flight. This was a compromise above the preferred 3.5 m altitude we have historically used with the T50. It was felt that higher altitudes would create unacceptable potential for swath displacement.
Rotary atomizer design is not standardized, and as a result, the droplet size selected on the controller did not necessarily produce the desired results. The Hybrid configuration was programmed to emit 350 µm droplets, selected as a compromise between drift mitigation and coverage potential. To offset the Mister nozzles’ reputation for producing a finer spray, the Orchard configuration was set to the maximum 500 µm. Operations settings are noted in Table 1.
Configuration
Nozzle
Droplet size (µm)
Speed (m/s)
Altitude (m)
Programmed Swath Width (m)
Application Volume (L/ha)
Hybrid
4 Sprinklers
350
8, 10, 12, 14, 16, 18, 20
4
7
30
Orchard
2 Misters, 2 Sprinklers
500
8, 10, 12, 14, 16, 18, 20
4
7
30
Table 1 – Operational settings for trials.
Three repetitions of seven speeds were flown for each configuration. Anticipating an increase in temperature and wind speed throughout the day, it was decided move through all seven speeds (a single repetition) before resetting and doing so two more times. The intent was to preclude confounding weather effects. Ideally, we should have alternated between configurations as well, but this proved impractical. As a result, we flew the Hybrid configuration first and the Orchard configuration last.
Weather
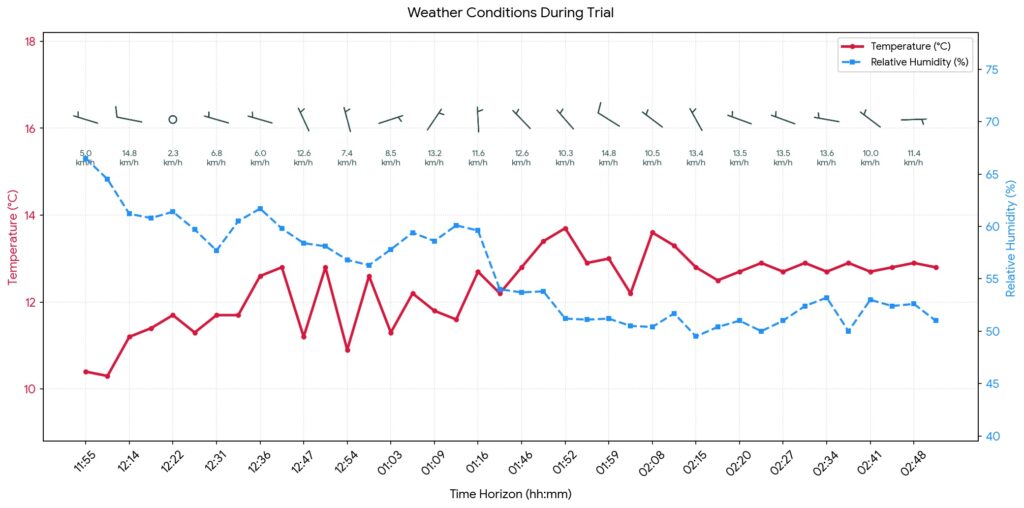
Weather data was collected using a Kestrel 3550AG weather meter (Kestrel Instruments) in a vane mount positioned 2.5 m above ground. Temperature and relative humidity were comparable throughout the ~3 hours of data collection, but as anticipated, wind speed was higher for the later Orchard configuration passes.
As previously indicated, wind direction shifted from an ideal headwind situation just before trials began, and was somewhat changeable, but the average wind direction for the two configurations was comparable (Figure 4 and Table 2).
Figure 4 – Weather conditions recorded at roughly 10-minute intervals, corresponding to the drone passing over the sampler.
Time
Configuration Flown
Average Temperature (°C)
Average Relative Humidity (%)
Average Wind Speed (km/h ± SD)
Average Direction (° ± SD)
11:55 am – 1:16 pm
Hybrid
11.7
59.9
8.4 ± 3.5
323 ± 46
1:43 pm – 2:52 pm
Orchard
12.9
51.6
11.9 ± 2.5
316 ± 48
Table 2 – Average weather conditions for the Hybrid configuration passes and for the Orchard configuration passes.
Collector analysis
Bond paper digitization
Bond papers were scanned using a Swath Gobbler™ (Application Insight LLC). The software measured deposition as both percent area covered (% area) and deposit density (deposits/cm2) every 100 mm, with a thresholded Hue of 23-280, a Saturation of 5-120 and a Value of 156-255.
Effective swath width calculation
The large data set produced by each pass was reduced in size by averaging the deposition for every 50 cm. This data was entered into our Excel-based swath width calculator, which assumes a racetrack pattern and sums deposits from adjacent swaths. The resulting swath width for each pass was the maximum width that minimized over- and under-dosing as well as the coefficient of variation (CV).
Analysis
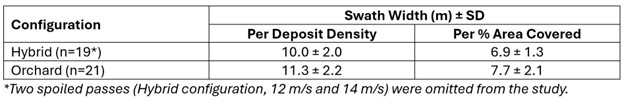
The average swath width derived from deposit density data was wider than that derived from percent area covered (Table 3).
Table 3 – Group means and standard deviation for average swath widths derived from deposit density data and percent coverage data. The average CV was between 29 and 32%.
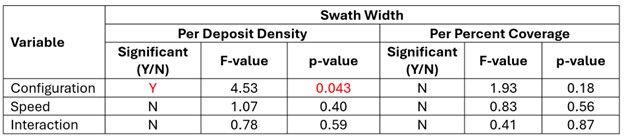
A two-way ANOVA (Analysis of Variance; α = 0.05) was performed to determine any significant effect of speed or configuration on swath width (Table 4). Flight speed had no significant effect on swath width, no matter how it was derived (% area covered or deposit density), for either configuration (Hybrid or Orchard). However, the average swath width derived from deposit density was significantly wider for the Orchard configuration compared to the Hybrid and presented higher variability.
Table 4 – Results of two-way ANOVA, exploring interactions between speed, swath width and configuration (95% confidence interval).
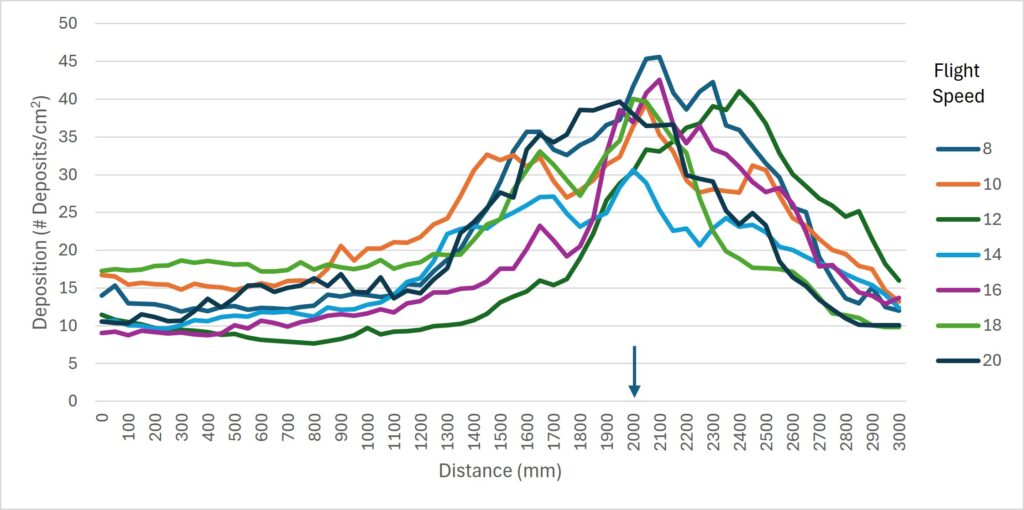
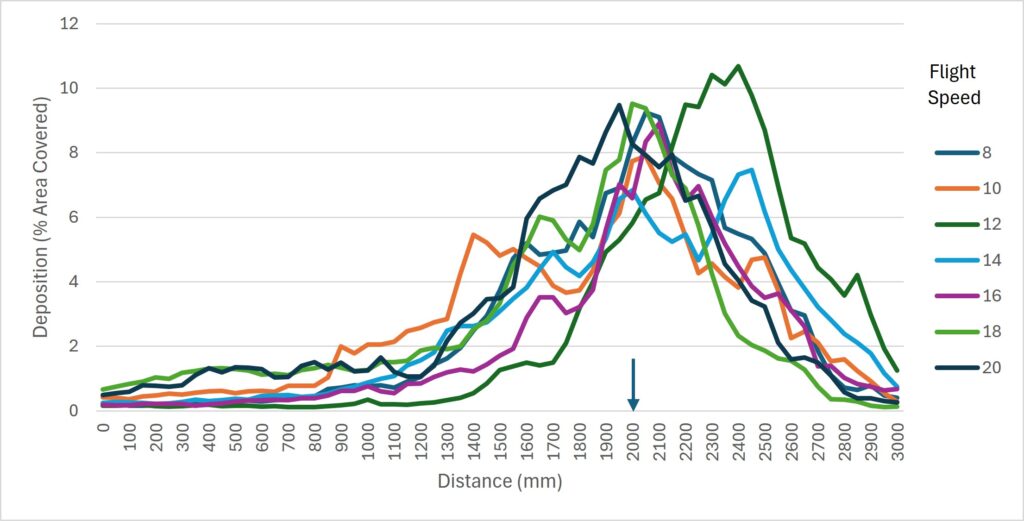
Orchard configuration was prone to displacement in a side wind. Shifting the flight path 5 m upwind improved the downwind capture, but for some flights it did trim a small portion of the upwind deposition. Deposit density gives greater resolution and exposes more variability than percent area covered. Figure 5 shows the average deposition by speed based on deposit density. Figure 6 shows the average deposition by speed based on percent area covered.
Figure 5 – Average deposition by speed based on deposit density. Arrow indicates flight path.Figure 6 – Average deposition by speed based on percent area covered. Arrow indicates flight path.
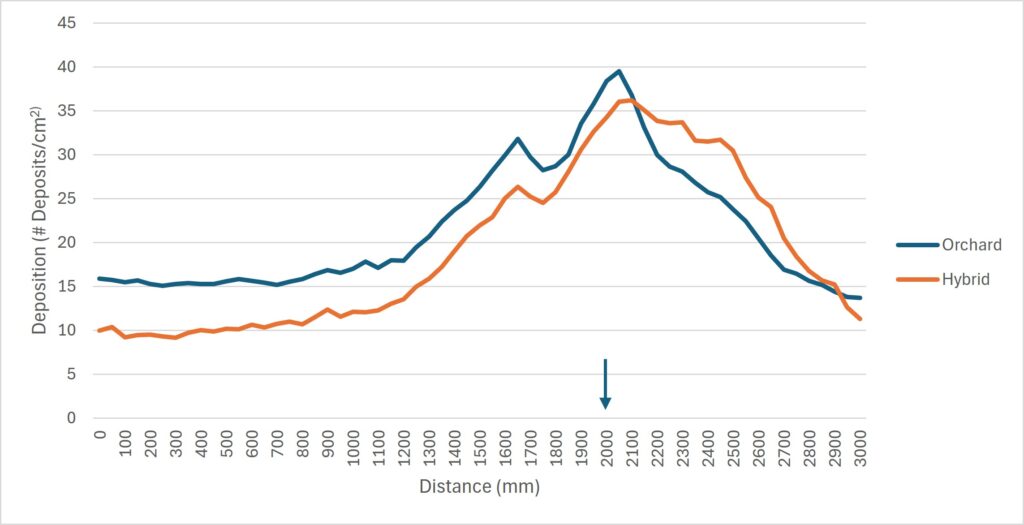
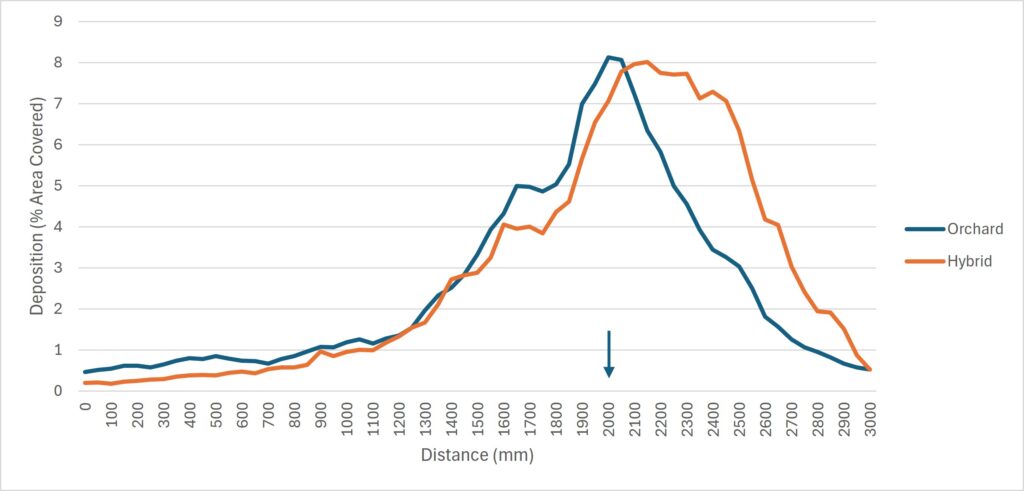
Figure 7 shows the average deposition by configuration based on deposit density. Figure 8 shows the average deposition by configuration, based on percent area covered. Based on deposit density, there were 55% more deposits on the downwind side of the sampler for Orchard configuration set to set to 500 microns compared to the Modified configuration set to 350 microns.
Figure 6 – Average deposition by configuration based on deposit density. Arrow indicates flight path.Figure 8 – Average deposition by configuration based on percent area covered. Arrow indicates flight path.
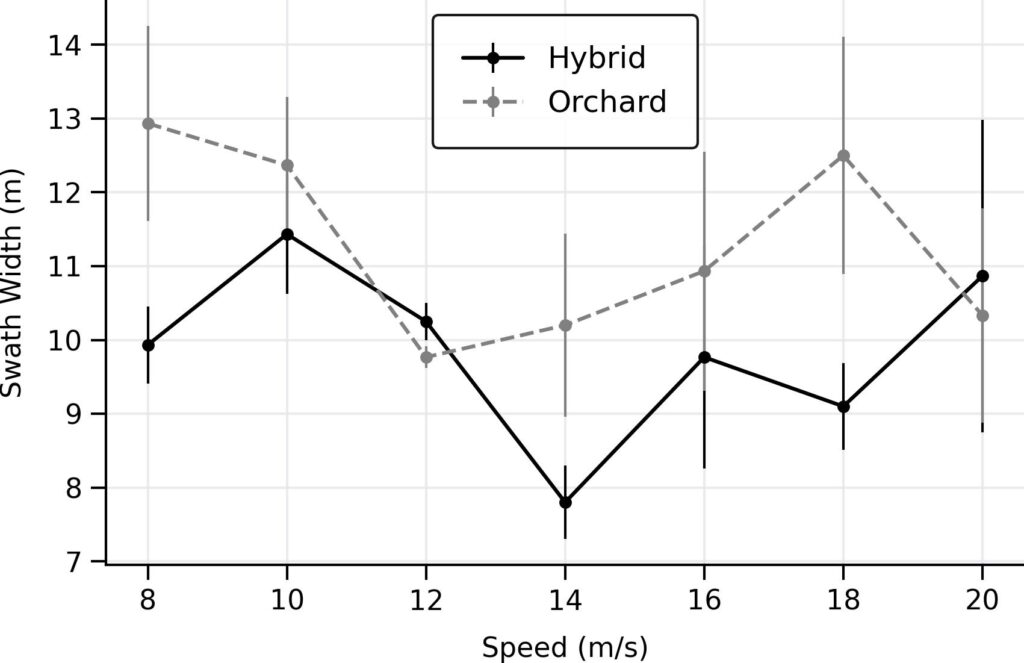
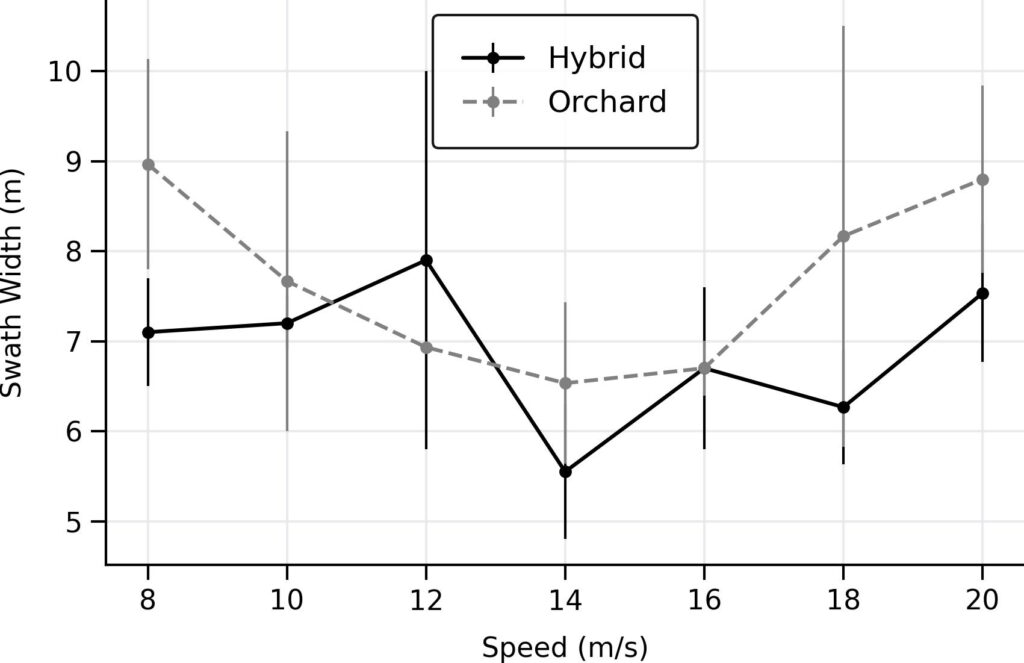
The average swath widths calculated from deposit density (Figure 9) and percent area covered (Figure 10) are shown with standard deviation. While it appears the swath width is less around 14 m/s, it is statistically insignificant and the response to speed is essentially flat. As with prior studies, swath widths calculated from deposit density are larger than those calculated from percent area covered.
Figure 9 – Average swath widths for each speed, derived from deposit density data. SD shown. n=3 for each speed, while n=2 for Hybrid configuration at 12 m/s and 14 m/s.Figure 10 – Average swath widths for each speed, derived from percent coverage data. SD shown. n=3 for each speed, while n=2 for Hybrid configuration at 12 m/s and 14 m/s.
Observations
Previous studies demonstrated a direct and positive relationship between drone speed and swath width up to 8-10 m/s. Here, we see no further response after ~8 m/s. This supports the hypothesis that rotary-wing drone speed and swath width share an asymptotic relationship that inflects at ~8-10 m/s. Variability makes it difficult to determine an exact value.
Despite increasing the programmed droplet size to the maximum 500 microns for the Orchard condition, there was 55% more downwind deposition compared to the Hybrid condition, which was set to 350 microns. This supports the claim that the Mister nozzle produces a span of droplet sizes that include far more fines than the Sprinkler nozzle, and underpins the need for a better understanding of the spray quality produced by rotary atomizers.
Spraying at high speeds is not an advisable practice. While swath width is no longer affected after ~8 m/s, there are other considerations. Note that it required 200 m for the drone to reach the highest speed, and in a related study we have seen swath width taper during initial acceleration and final deceleration, leaving gaps in coverage.
Further, the minimum 5 m altitude advised by DJI ensures a safe margin for the drone to respond to obstacles and topography during high speed flight, but is not conducive to spraying. The author is aware of a situation where flying the T100 at 4 m altitude and 18 m/s over a canola field with rolling hills caused it to perform an emergency landing.
An ideal speed is one that maintains the most consistent swath width at a reasonable altitude.
Thanks to Drone Spray Canada and Bayer Canada for in kind and financial support, and thanks to Cesar Cappa, OMAFA horticulture weed specialist for his participation in the study.